メインコンテンツへスキップ
見出し画像

(定義を追記)中学でも分かる⑧「三角関数」

     前回までの三角比では、角度の範囲は 0°≦θ≦180°0\degree\leqq\theta\leqq180\degree でした。ここでは、その角度を任意の角度(一般角)まで拡張した三角関数を勉強します。
     前回やった単位円の議論を進め、新しい角度の測り方である弧度法まで内容を進めていきます。三角比の定義や単位円の復習から始めたい方は、前回の中学でも分かる➆「三角比」をご覧ください。
     なお、ここでは主に三角関数のグラフだけに話をとどめ、重要な公式については最後に紹介する程度にします(必要があれば別の記事で)。

    前回の復習

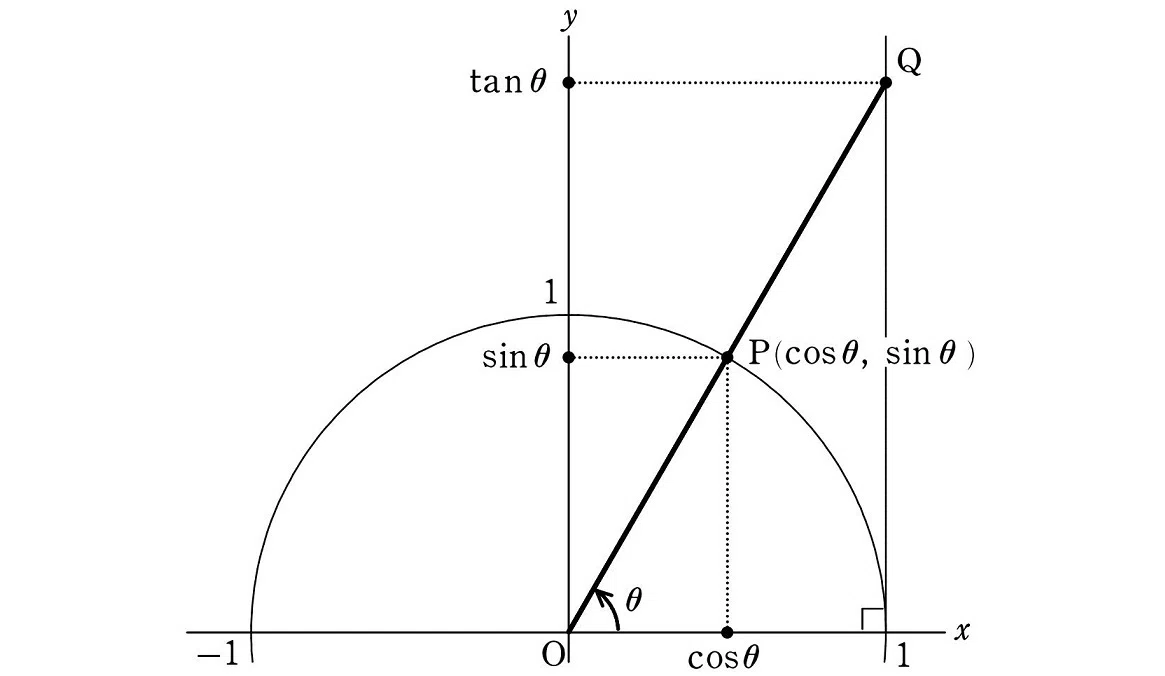
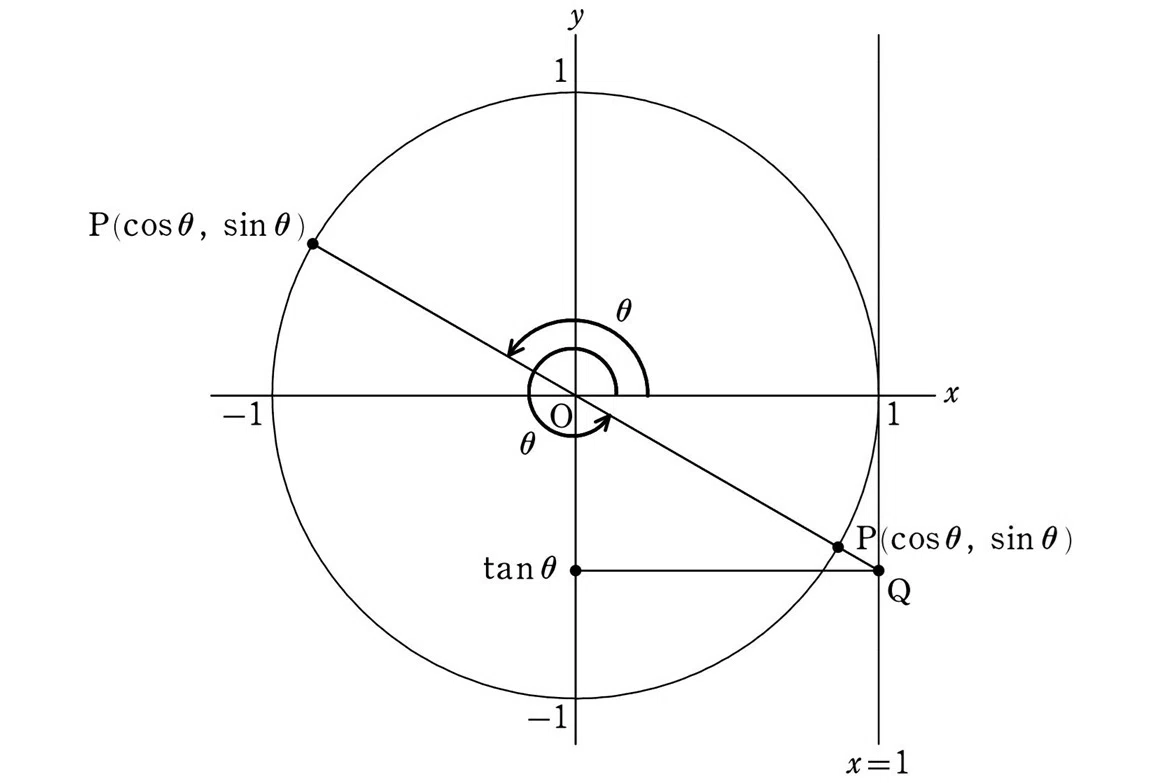
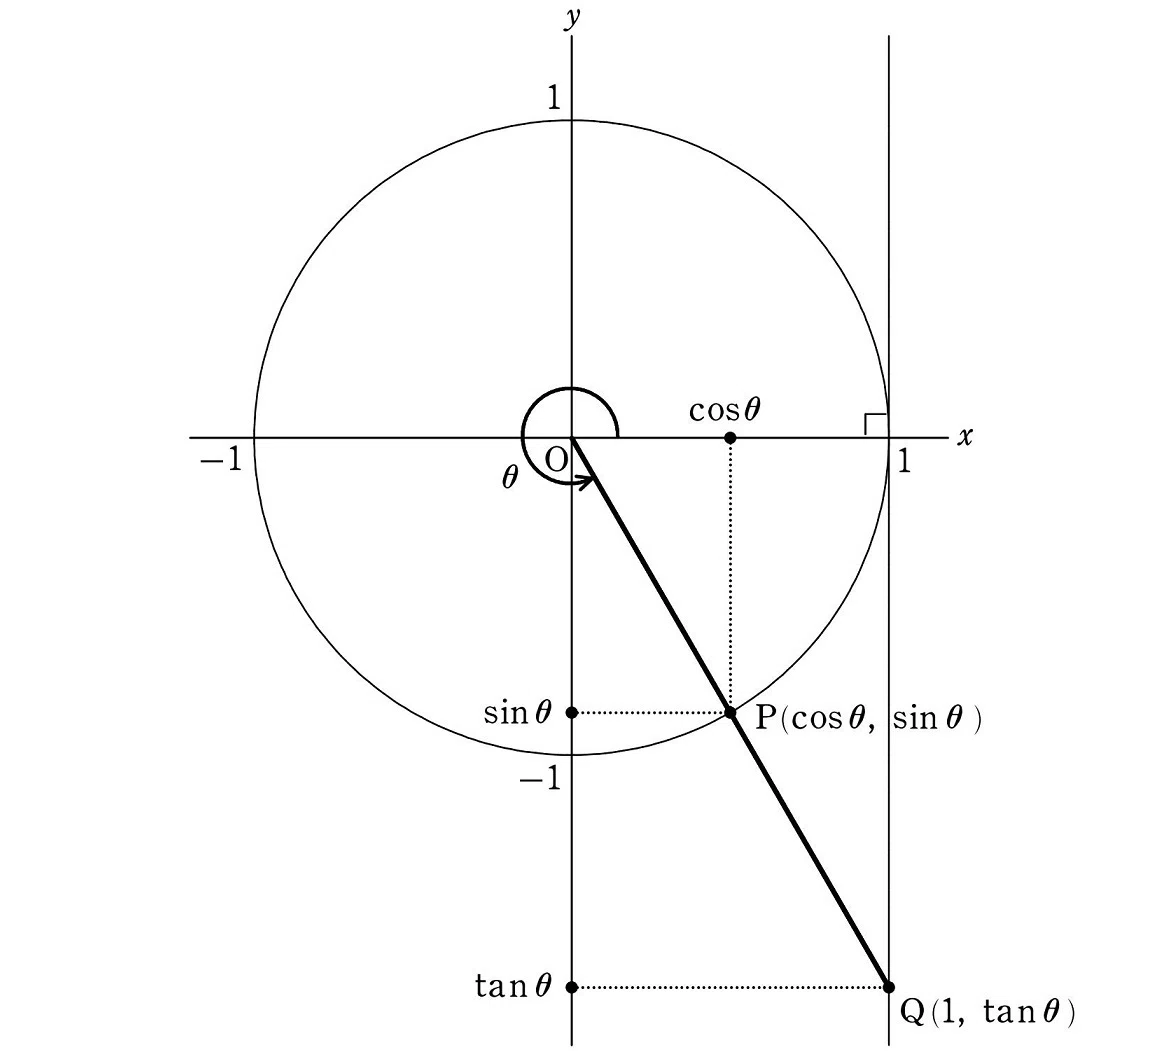
     前回の、中学でも分かる➆「三角比」では、sin⁡θ, cos⁡θ, tan⁡θ\sin\theta,  \cos\theta,  \tan\theta を単位円で考えました。 sin⁡θ, cos⁡θ\sin\theta,  \cos\theta は単位円周上の動点の座標、tan⁡θ\tan\theta は動径 OP\text{OP} の延長と直線 x=1x=1 の交点の yy 座標とみることができます。

    (case1) 鋭角、つまり 0°<θ<90°0\degree<\theta<90\degree のとき

    画像

     取り得る値の範囲は

    sin⁡θ>0cos⁡θ>0tan⁡θ>0\begin{alignat*}{2} &\sin\theta & &>0\\ &\cos\theta & &>0\\ &\tan\theta & &>0 \end{alignat*}

    となり、すべてプラスの値となります。
     tan⁡θ\tan\theta は、点 Q\text{Q} から yy 軸に垂線を下ろし、その交点との yy 座標と考えると、図形的にイメージしやすくなります。
     このように考えることによって、sin⁡θ, cos⁡θ, tan⁡θ\sin\theta,  \cos\theta,  \tan\theta のそれぞれの”居場所”がビジュアル化でき、これが単位円で考えるメリットになります。

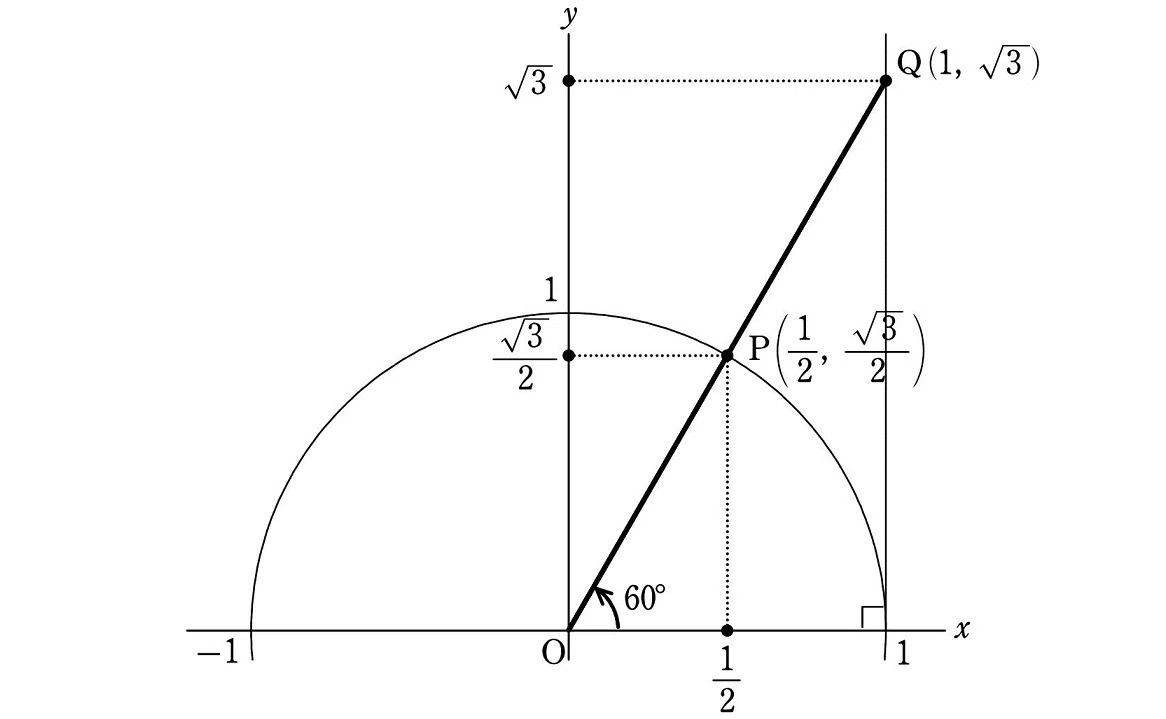
    例 60°60\degree の三角比は、下図より

    画像

     点 P\text{P} の座標は (12, 32)cos⁡60°sin⁡60°\underset{\hspace{1pt}\cos60\degree\hspace{0pt}\sin60\degree}{\left(\dfrac{1}{2},  \dfrac{\sqrt{3}}{2}\right)}
     点 Q\text{Q} の座標は (1,  3 )tan⁡60°\underset{\hspace{18pt}\tan60\degree}{(1,   \sqrt{3}\,)}
    なので

    sin⁡60°=32cos⁡60°=12tan⁡60°=3\begin{alignat*}{2} &\sin60\degree & &=\frac{\sqrt{3}}{2}\\[6pt] &\cos60\degree & &=\frac{1}{2}\\[10pt] &\tan60\degree & &=\sqrt{3} \end{alignat*}

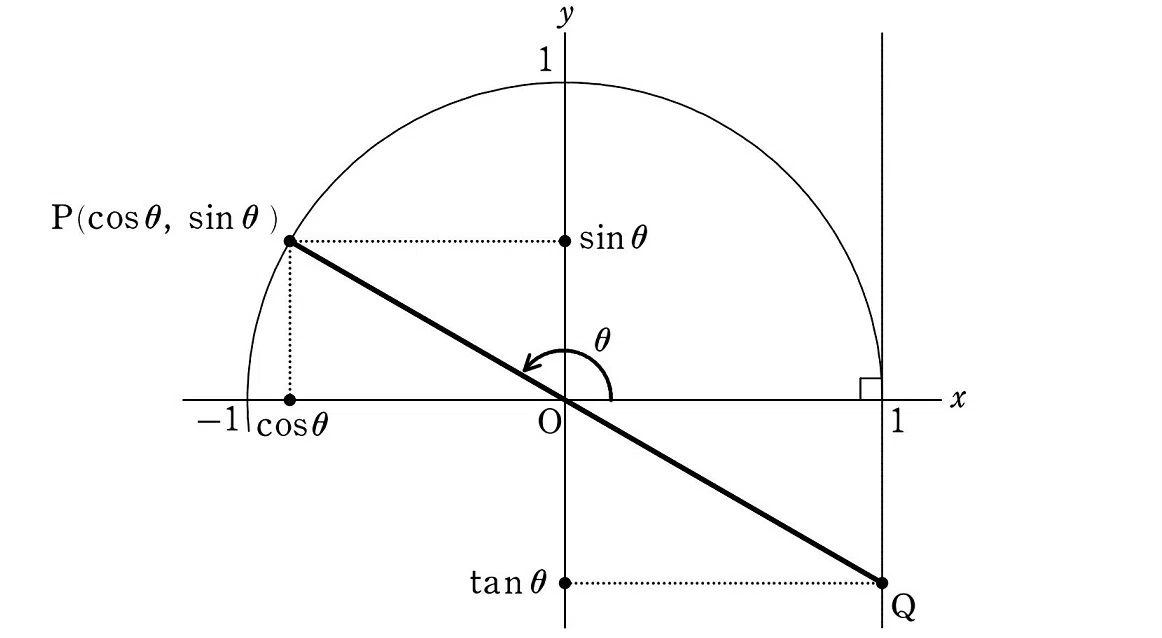
    (case2) 鈍角、つまり 90°<θ<180°90\degree<\theta<180\degree のとき

    画像

     取り得る値の範囲は

    sin⁡θ>0cos⁡θ<0tan⁡θ<0\begin{alignat*}{2} &\sin\theta & &>0\\ &\cos\theta & &<0\\ &\tan\theta & &<0 \end{alignat*}

    となり、cos⁡θ\cos\theta と tan⁡θ\tan\theta がマイナスの値をとります。sin⁡θ\sin\theta だけがプラスの値です。

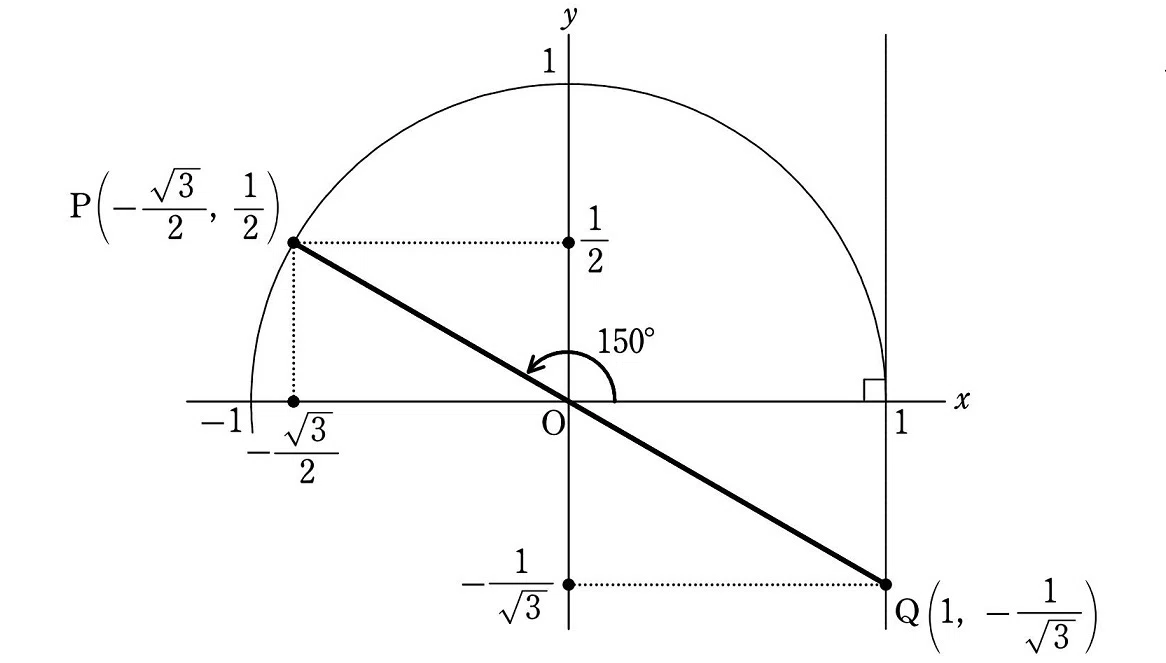
    例 150°150\degree の三角比は、下図より

    画像

     点 P\text{P} の座標は (−32, 12)cos⁡150°sin⁡150°\underset{\hspace{12pt}\cos150\degree\hspace{1pt}\sin150\degree}{\left(-\dfrac{\sqrt{3}}{2},  \dfrac{1}{2}\right)}
     点 Q\text{Q} の座標は  (1, −13)tan⁡150°\underset{\hspace{18pt}\tan150\degree}{\left(1,  -\dfrac{1}{\sqrt{3}}\right)}
    なので

    sin⁡150°=12cos⁡150°=−32tan⁡150°=−13\begin{alignat*}{2} &\sin150\degree & &=\frac{1}{2}\\[6pt] &\cos150\degree & &=-\frac{\sqrt{3}}{2}\\[6pt] &\tan150\degree & &=-\dfrac{1}{\sqrt{3}} \end{alignat*}

     ここまでは、前回の「三角比」でやりました。

    三角比を一般角に拡張

     ここから、角度の範囲を 0°≦θ≦180°0\degree\leqq\theta\leqq180\degree から任意の角度(一般角)に拡張します。つまり、単位円をぐるぐる回る円関数と考えます。
     まずは、一般角について定義を与えます。

    一般角

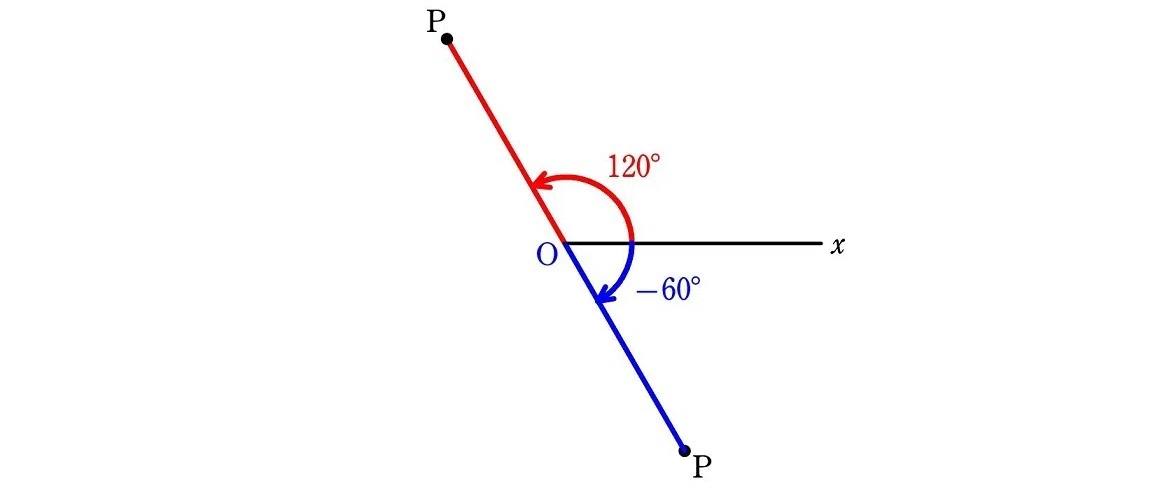
     動径 OP\text{OP} が O\text{O} の周りを回転するとき、xx 軸の正の部分(始線)から反時計回り(正の方向)に測った角を正の角、時計回り(負の方向)に測った角を負の角とする。角度は xx 軸の正の部分から測ることに注意。これを始線という。
     例えば、正の角 120°120\degree、負の角 −60°-60\degree は下図のようになる。

    画像

     動径 OP\text{OP} が O\text{O} の周りを回転すると、その回転量に応じて、いくらでも絶対値の大きい角度が考えられる。このように角を”回転の量”ととらえ、360°360\degree より大きい角や、負の角まで意味をひろげた角を一般角という。
     360°360\degree 回転すると、動径はちょうど 11 回転してもとと同じ位置にくる。したがって、1つの動径 OP\text{OP} と始線とのなす角は無数に考えられるが、その1つを a°a\degree とすると、OP\text{OP} を表す一般角 θ\theta は次の式で表される。

    θ=a°+360°×n(n は整数)\begin{align*} \theta=a\degree+360\degree\times n\small{(n  は整数)} \end{align*}

    ***

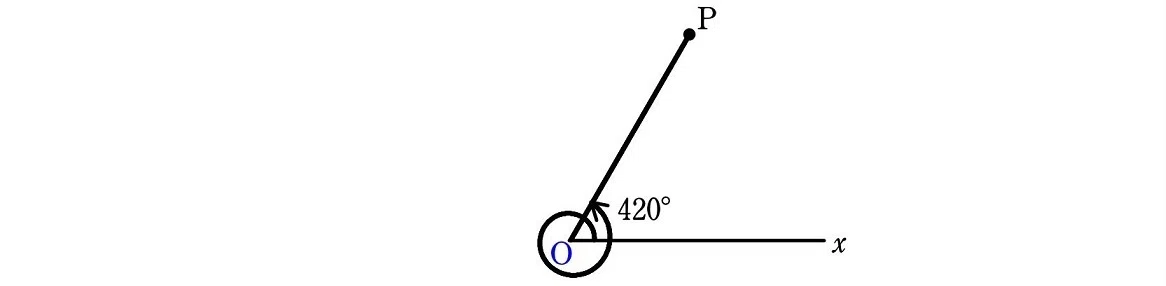
    例1 420°420\degree は
      420°=60°+360°×1420\degree=60\degree+360\degree\times1
    で表せます。

    画像

     半時計周りに1周回って 60°60\degree 進んだ角度です。

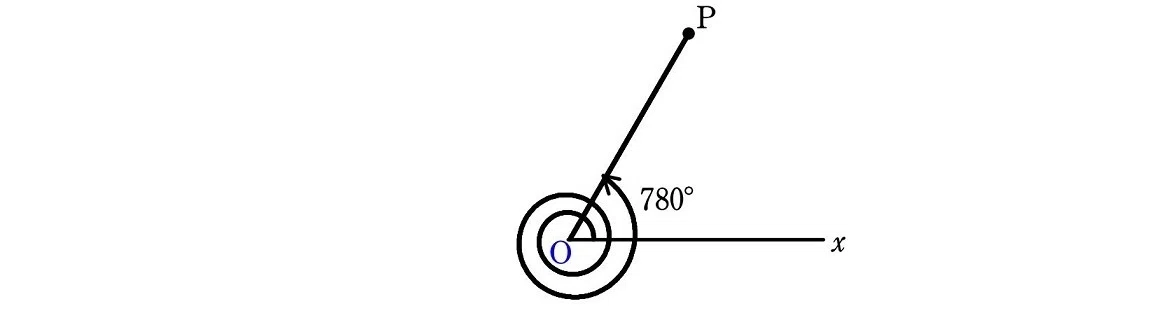
    例2 780°780\degree は
      780°=60°+360°×2780\degree=60\degree+360\degree\times2
    で表せます。

    画像

     半時周りに2周回って 60°60\degree 進んだ角度です。

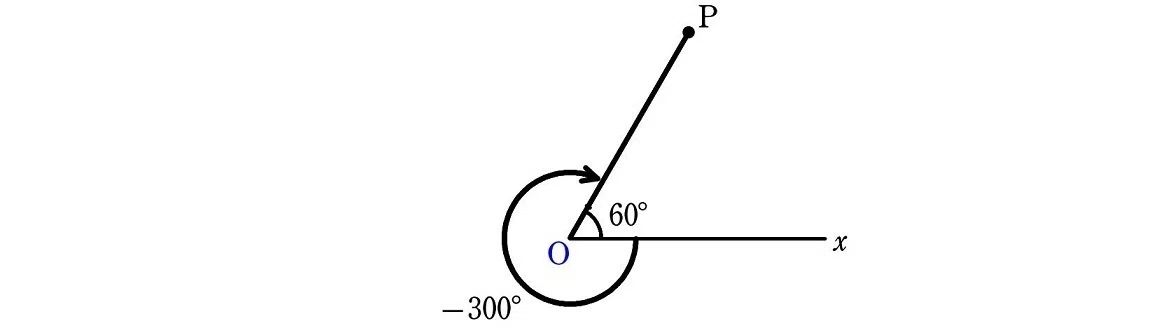
    例3 −300°-300\degree は
      −300°=60°+360°×(−1)-300\degree=60\degree+360\degree\times(-1)
    で表せます。

    画像

     負の角なので、時計回りに 300°300\degree 進んだ角度です。
     すると、例1、例2、例3はすべて同じ動径を表し、60°60\degree のときと同じであることが分かります。よって、このときの動径 OP\text{OP} を表す一般角 θ\theta は

    θ=60°+360°×n(n は整数)\begin{align*} \theta=60\degree+360\degree\times n\small{(n  は整数)} \end{align*}

    となります。

    三角関数

     三角比 sin⁡θ, cos⁡θ, tan⁡θ\sin\theta,  \cos\theta,  \tan\theta はいずれも θ\theta の関数です。θ\theta が決まれば、それぞれの三角比は一通りにきまります。そこで三角比を一般角で定義します。θ\theta を一般角で定義した sin⁡θ, cos⁡θ, tan⁡θ\sin\theta,  \cos\theta,  \tan\theta を三角関数といいます。

     あらためて、教科書的に三角関数の定義を与えます。
     三角関数とは、前回の<三角比の定義>を一般角に対しても成り立つように拡張し、角度を入力とする新しい関数としてとらえ直したものです。

    <三角関数の定義>

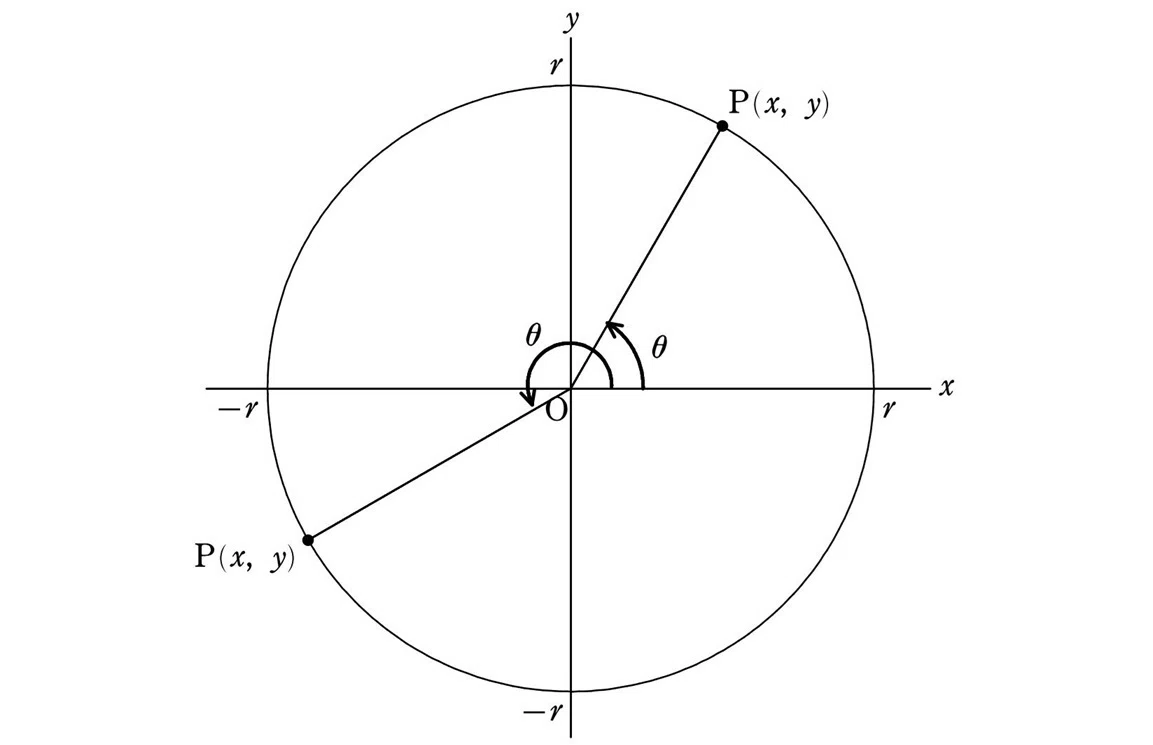
     座標平面において、中心が原点 O\text{O}、半径が rr の円を考える。xx 軸の正の部分(始線)と動径 OP\text{OP} のなす反時計回りの角(一般角)を θ\theta とする。

    画像

     このとき、点 P(x, y)\text{P}(x,  y) とすると、三角関数 sin⁡θ, cos⁡θ, tan⁡θ\sin\theta,  \cos\theta,  \tan\theta は次のように定義される。

    sin⁡θ=yrcos⁡θ=xrtan⁡θ=yx\begin{align*} \sin\theta&=\dfrac{y}{r}\\[8pt] \cos\theta&=\dfrac{x}{r}\\[8pt] \tan\theta&=\dfrac{y}{x} \end{align*}

    ***

     定義式自体は<三角比の定義>と同じですが、扱える角度が三角比の 0°≦θ≦180°0\degree\leqq\theta\leqq180\degree から、一般角へと拡張されています。
     ここで、sin⁡θ, cos⁡θ\sin\theta,  \cos\theta について、両辺に rr を掛けると

    y=rsin⁡θx=rcos⁡θ\begin{align*} y&=r\sin\theta\\ x&=r\cos\theta \end{align*}

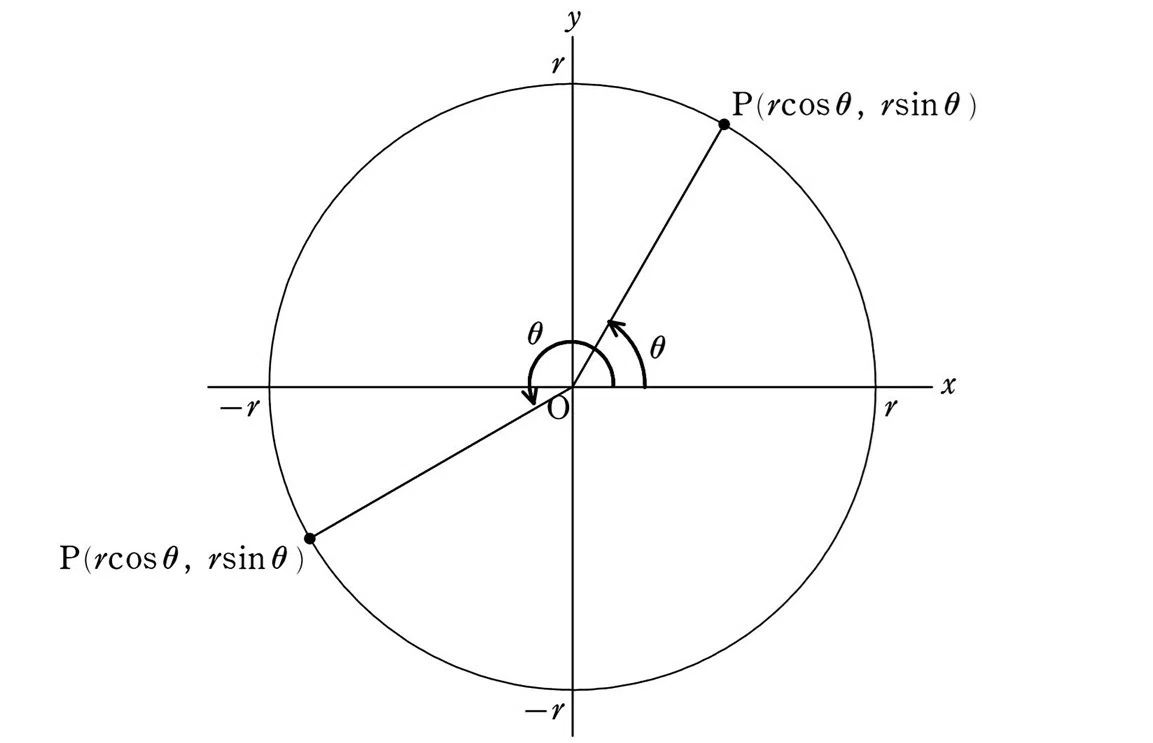
     したがって、点 P(x, y)\text{P}(x,  y) の座標は、半径 rr と三角関数 sin⁡θ, cos⁡θ\sin\theta,  \cos\theta を用いて

    P(rcos⁡θ, rsin⁡θ)\begin{align*} \text{P}(r\cos\theta,  r\sin\theta) \end{align*}

    と表せます。

    画像

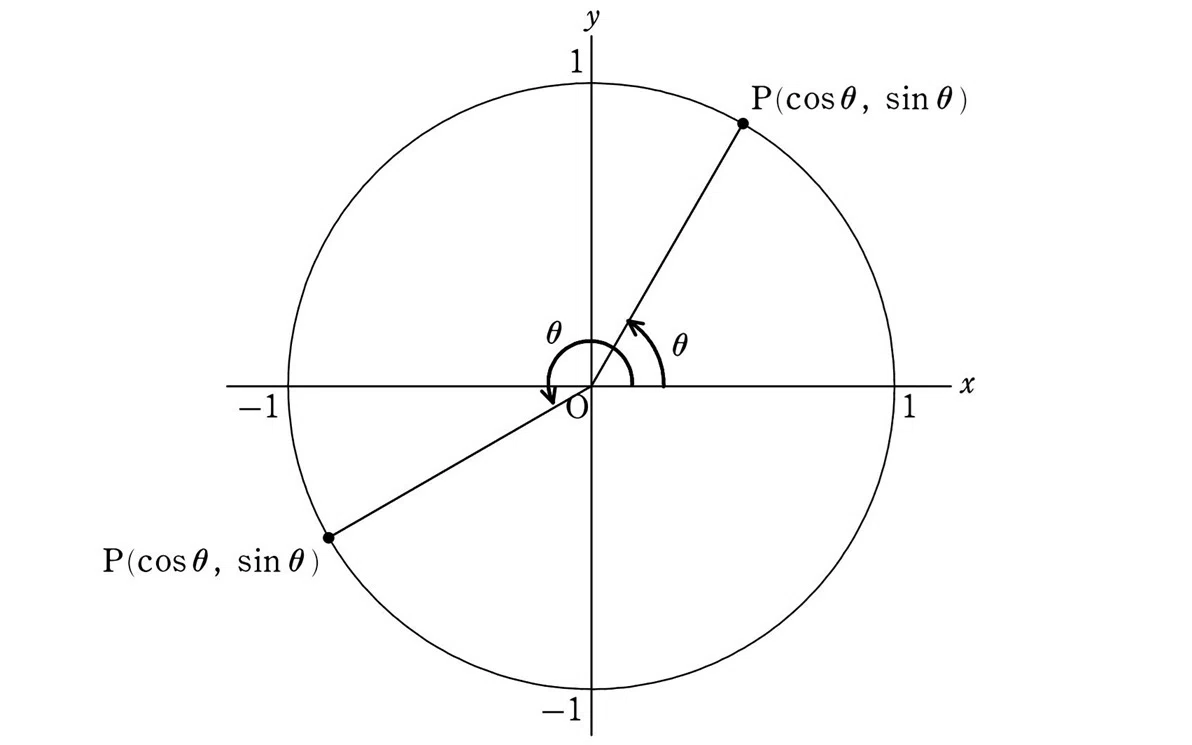
     ここで、半径を r=1r=1 としましょう。この中心が原点で、半径 11 の円を単位円といいます。このとき、単位円周上の点 P\text{P} の座標は、三角関数だけを用いて次のように表せます。

    P(cos⁡θ, sin⁡θ)\begin{align*} \text{P}(\cos\theta,  \sin\theta) \end{align*}

    画像

     tan⁡θ\tan\theta についても、単位円周上ではどこに現れるのかを示すために、より詳しくみていきましょう。
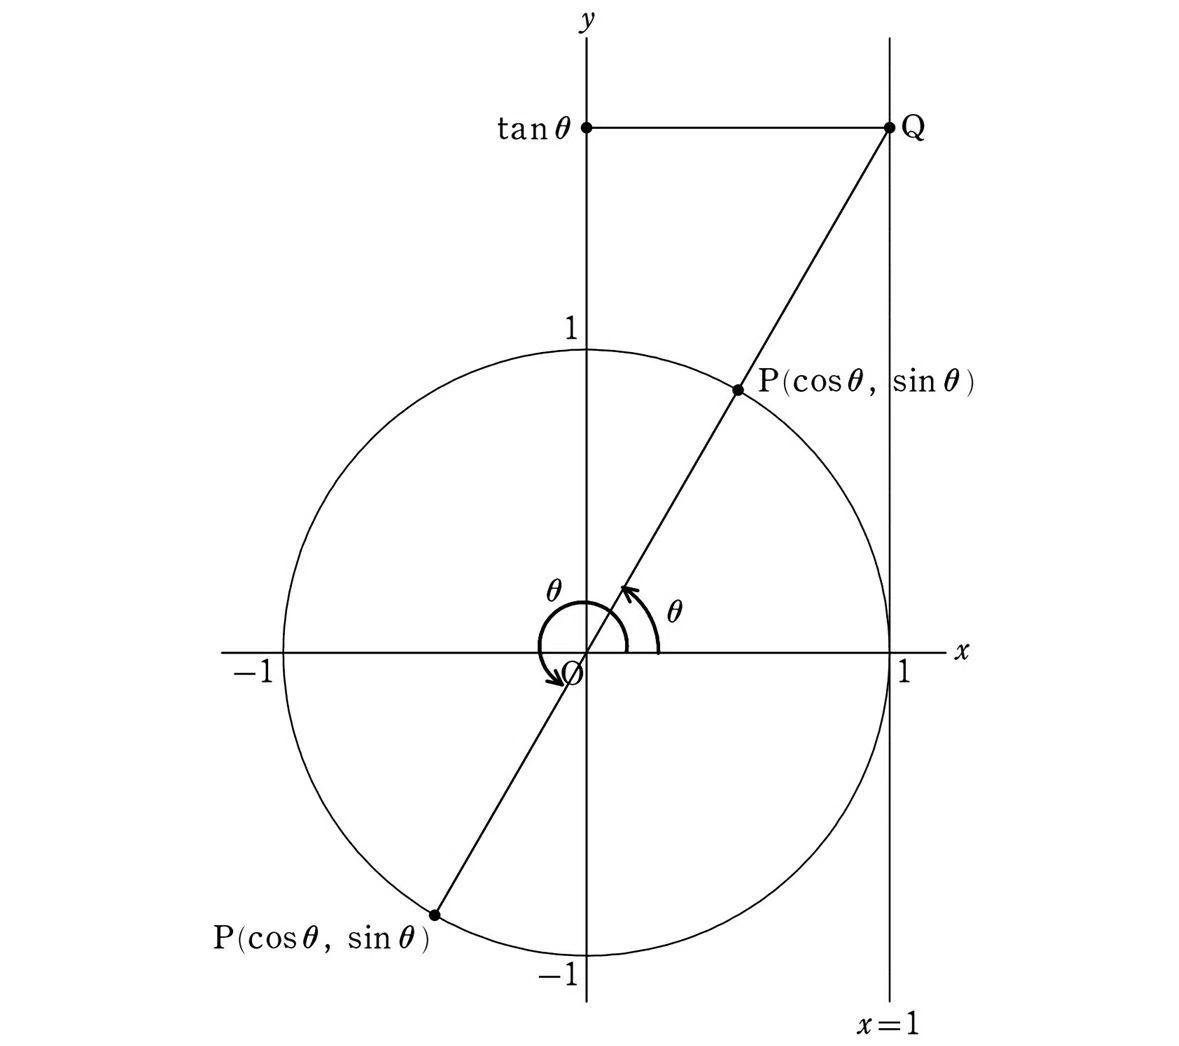
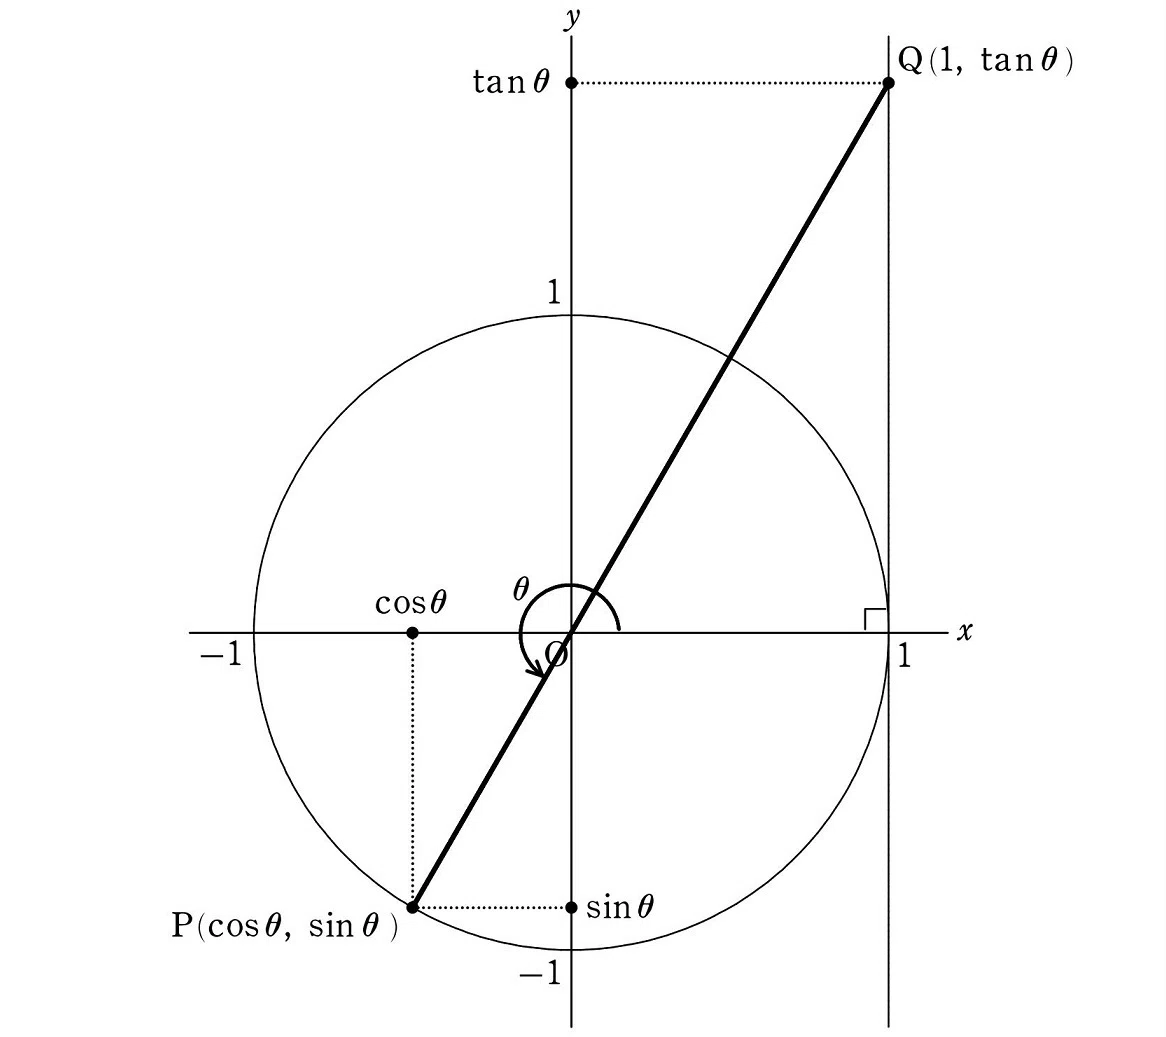
     sin⁡θ, cos⁡θ, tan⁡θ\sin\theta,  \cos\theta,  \tan\theta の各三角関数は、単位円周上で次のように視覚化できます。

    (ⅰ) 点 P(x, y)\text{P}(x,  y) が第1象限(0°<θ<90°0\degree<\theta<90\degree)、または第3象限(180°<θ<270°180\degree<\theta<270\degree)にあるとき。

    画像

     三角関数 sin⁡θ, cos⁡θ\sin\theta,  \cos\theta は、単位円周上の点の座標となります。
     特に tan⁡θ\tan\theta は、直線 OP\text{OP} と直線 x=1x=1 との交点の yy 座標として特徴付けられます。三角関数の新しい意味づけです(中学でも分かる⑦「三角比」)。

    (ⅱ) 点 P(x, y)\text{P}(x,  y) が第2象限(90°<θ<180∘90\degree<\theta<180^{\circ})、または第4象限(270°<θ<360°270\degree<\theta<360\degree)にあるとき

    画像

     このときも tan⁡θ\tan\theta は、直線 OP\text{OP} と直線 x=1x=1 との交点の yy 座標として特徴付けられます。その交点 yy 座標が、 xx 軸より下のエリアになることに注意してください(中学でも分かる⑦「三角比」)。
     このように、単位円を用いることで、各三角関数に図形的な新しい意味を与えることができます。

     0°≦θ≦180°0\degree\leqq\theta\leqq180\degree のときの三角関数の考え方は、先ほど復習した通りです。その拡張として、先ほどの単位円を用いて、180°180\degree より大きな角度についての三角関数をみていきます。

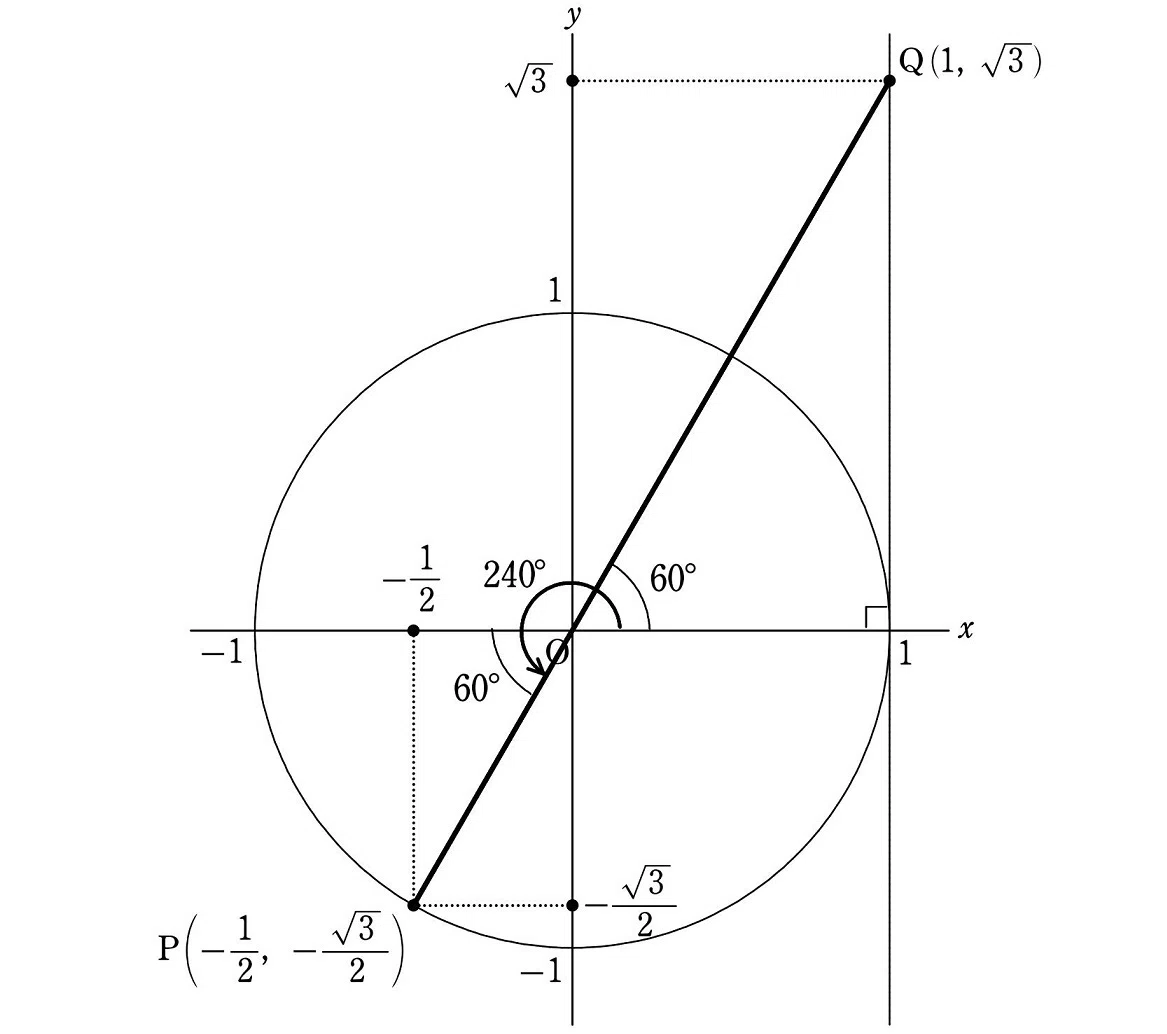
     例えば、240°240\degree の三角関数の値は、下図より

    画像

     点 P\text{P} の座標は (−12, −32)cos⁡240°sin⁡240°\underset{\hspace{1pt}\cos240\degree\hspace{5pt}\sin240\degree}{\left(-\dfrac{1}{2},  -\dfrac{\sqrt{3}}{2}\right)}
     点 Q\text{Q} の座標は (1,  3 )tan⁡240°\underset{\hspace{18pt}\tan240\degree}{(1,   \sqrt{3}\,)}
    なので

    sin⁡240°=−32cos⁡240°=−12tan⁡240°=3\begin{alignat*}{2} &\sin240\degree & &=-\frac{\sqrt{3}}{2}\\[6pt] &\cos240\degree & &=-\frac{1}{2}\\[10pt] &\tan240\degree & &=\sqrt{3} \end{alignat*}

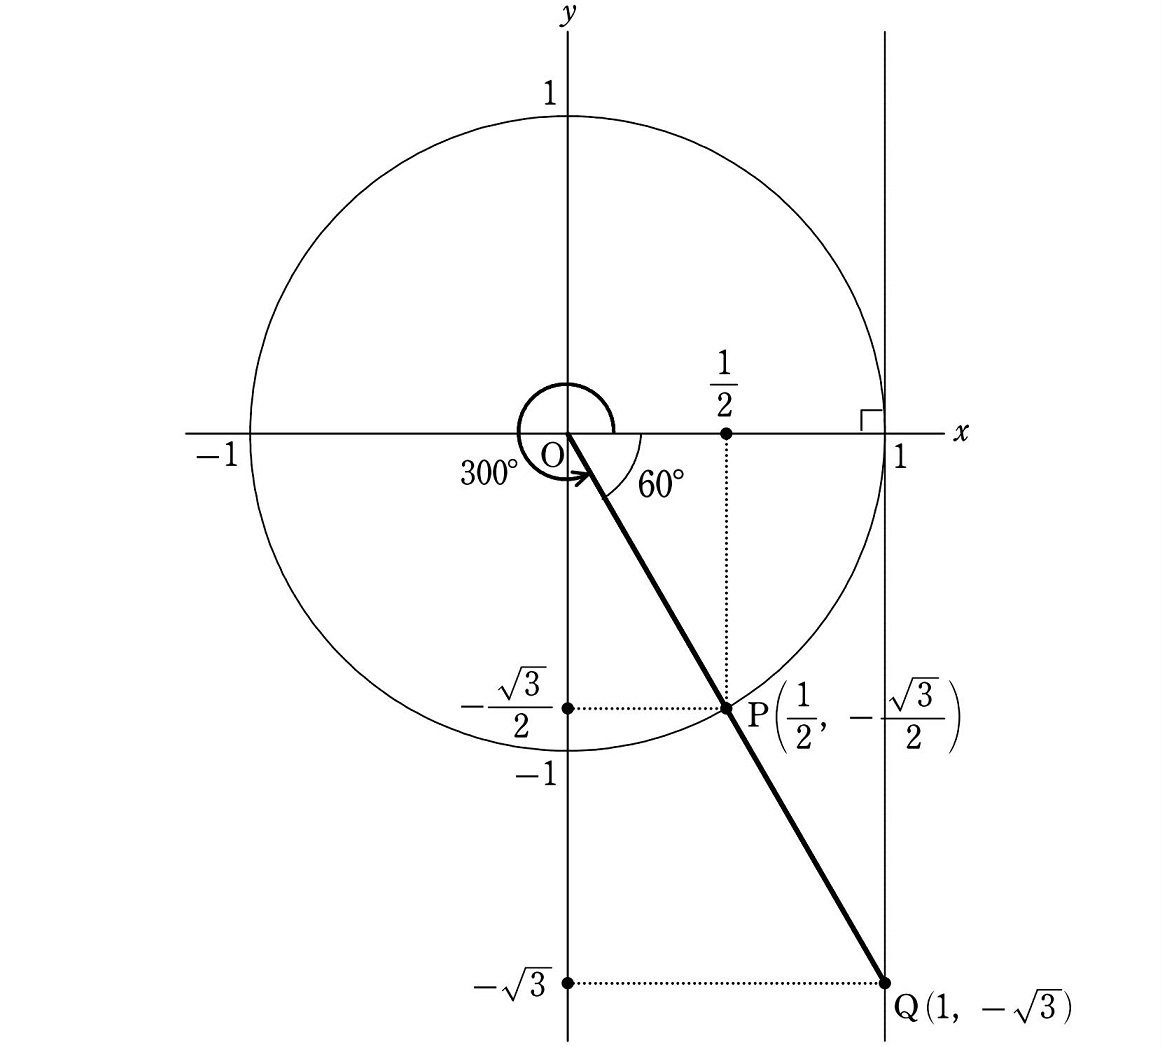
     300°300\degree の三角関数の値は、下図より

    画像

     点 P\text{P} の座標は (12, −32)cos⁡300°sin⁡300°\underset{\hspace{-2pt}\cos300\degree\hspace{3pt}\sin300\degree}{\left(\dfrac{1}{2},  -\dfrac{\sqrt{3}}{2}\right)}
     点 Q\text{Q} の座標は (1, −3 )tan⁡300°\underset{\hspace{18pt}\tan300\degree}{(1,  -\sqrt{3}\,)}
    なので

    sin⁡300°=−32cos⁡300°=12tan⁡300°=−3\begin{alignat*}{2} &\sin300\degree & &=-\frac{\sqrt{3}}{2}\\[6pt] &\cos300\degree & &=\frac{1}{2}\\[10pt] &\tan300\degree & &=-\sqrt{3} \end{alignat*}

    と決定されます。
     一般に、次のようにまとめられます。

    (case3) 180°<θ<270°180\degree<\theta<270\degree のとき

    画像

     取り得る値の範囲は

    sin⁡θ<0cos⁡θ<0tan⁡θ>0\begin{alignat*}{2} &\sin\theta & &<0\\ &\cos\theta & &<0\\ &\tan\theta & &>0 \end{alignat*}

    となり、sin⁡θ\sin\theta と cos⁡θ\cos\theta がマイナスの値をとります。tan⁡θ\tan\theta だけがプラスの値です。

    (case4) 270°<θ<360°270\degree<\theta<360\degree のとき

    画像

     取り得る値の範囲は

    sin⁡θ<0cos⁡θ>0tan⁡θ<0\begin{alignat*}{2} &\sin\theta & &<0\\ &\cos\theta & &>0\\ &\tan\theta & &<0 \end{alignat*}

    となり、sin⁡θ\sin\theta と tan⁡θ\tan\theta がマイナスの値をとります。cos⁡θ\cos\theta だけがプラスの値です。

    sinθ、cosθ のグラフ

     ここから、三角関数のグラフを考えましょう。
     前回やりましたが、0°≦θ≦180°0\degree\leqq\theta\leqq180\degree のときの sin⁡θ\sin\theta と cos⁡θ\cos\theta の値は次のようになります。

     0°30°45°60°90°120°135°150°180°sin⁡012223213222120cos⁡13222120−12 −22 −32−1\def\arraystretch{1.5} \begin{array}{c|c|c|c|c|c|c|c|c|c}   & 0\degree & 30\degree & 45\degree & 60\degree & 90\degree & 120\degree & 135\degree & 150\degree & 180\degree\\ \hline \sin & 0 & \frac{1}{2} & \frac{\sqrt{2}}{2} & \frac{\sqrt{3}}{2} & 1 & \frac{\sqrt{3}}{2} & \frac{\sqrt{2}}{2} & \frac{1}{2} & 0\\ \hline \cos & 1 & \frac{\sqrt{3}}{2} & \frac{\sqrt{2}}{2} & \frac{1}{2} & 0 & -\frac{1}{2} & -\frac{\sqrt{2}}{2} & -\frac{\sqrt{3}}{2} & -1 \end{array}

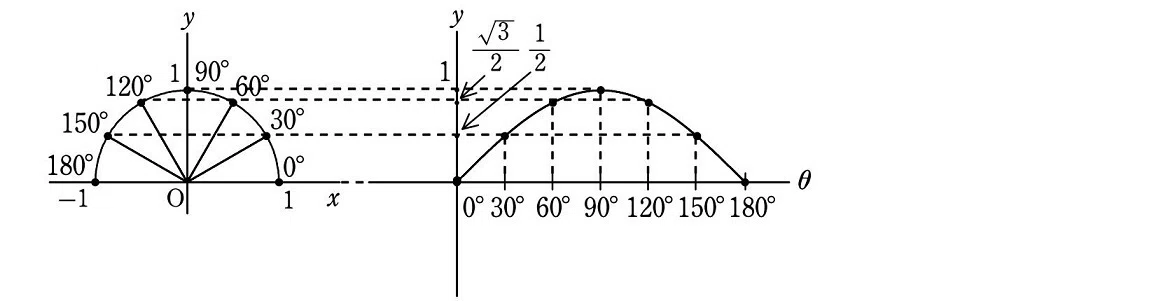
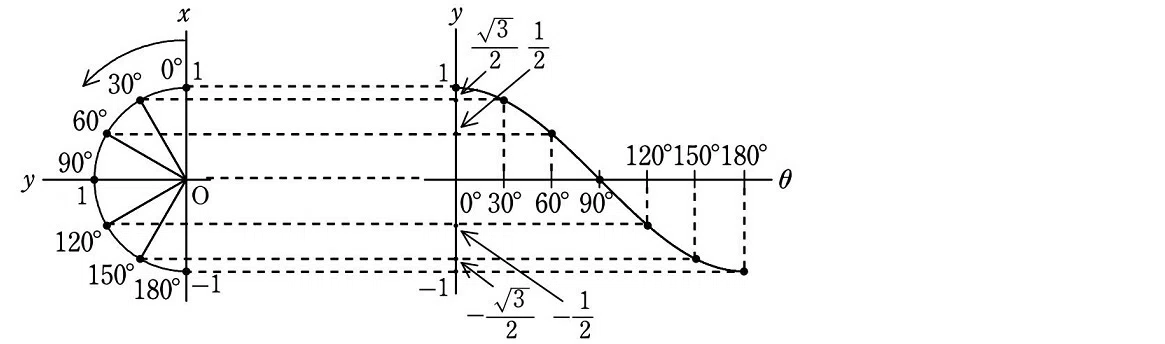
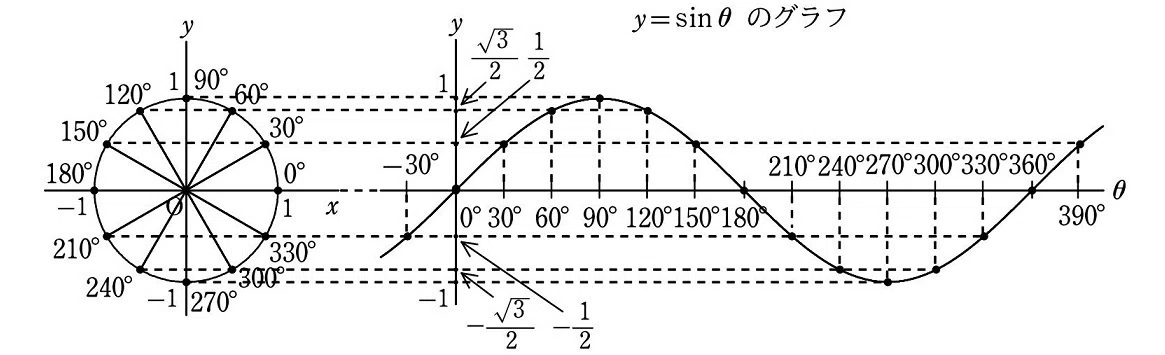
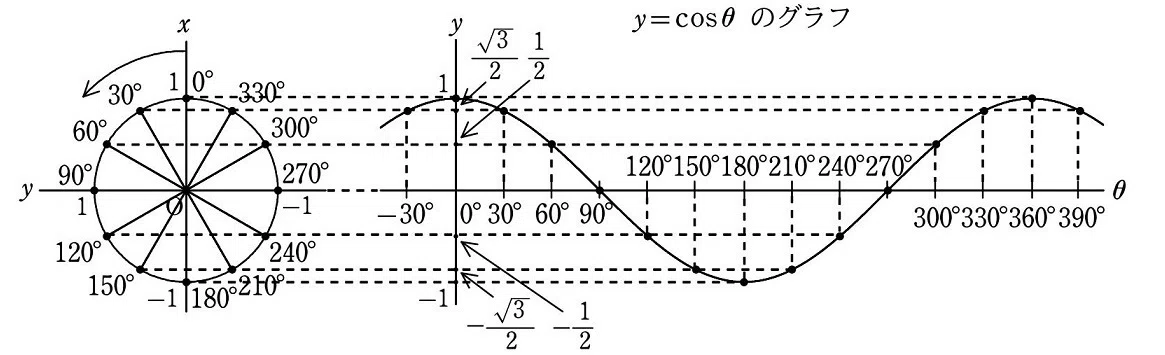
     関数 y=sin⁡θy=\sin\theta、y=cos⁡θy=\cos\theta と見立てて、この値を 30°30\degree 刻みで y−θy-\theta 座標にプロットしていくと、下図のようになります。

    y=sin⁡θy=\sin\theta について

    画像

     sin⁡θ\sin\theta の値は単位円周上の yy 座標なので、それぞれの θ\theta に対して yy の値を横にスライドさせていけば y=sin⁡θy=\sin\theta のグラフが得られます。
     ちょうど θ=90°\theta=90\degree のとき最大値 11 を取り、なだらかな山のような形です。

    y=cos⁡θy=\cos\theta について

    画像

     cos⁡θ\cos\theta の値は単位円周上の xx 座標なので、xx 軸が縦になるように、単位円を反時計回りに 90°90\degree 回転させています。もちろん、角度は xx 軸の正の部分(始線)からの角度です(上図の矢印)。 それぞれの θ\theta に対して xx の値を横にスライドさせていけば y=cos⁡θy=\cos\theta のグラフが得られます。

     これを、すべての角度 θ\theta に拡張します。
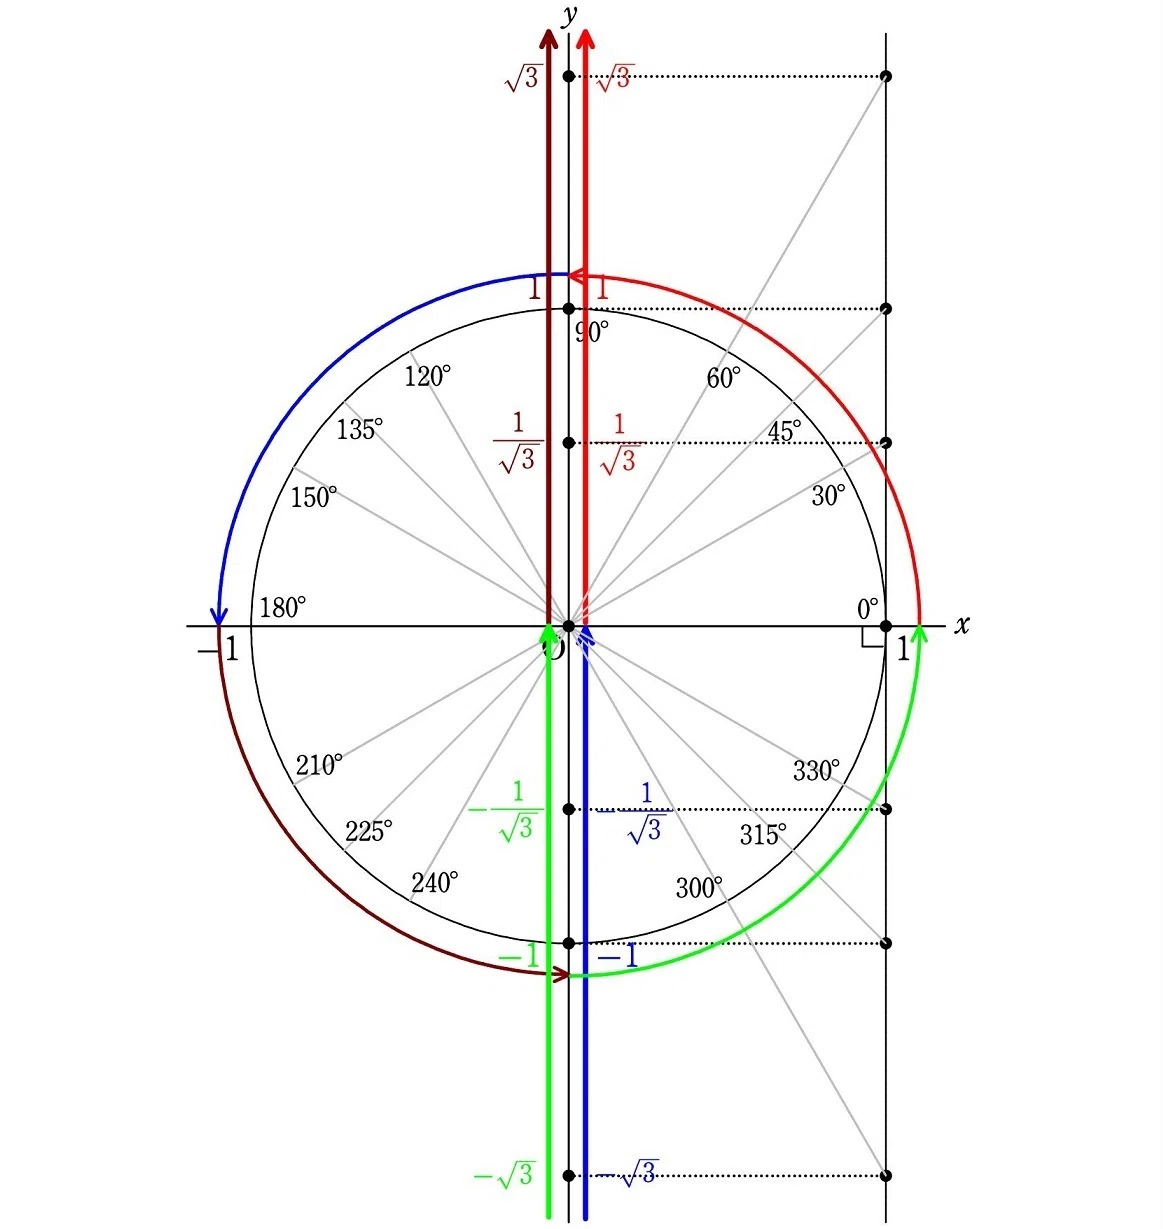
     はじめに、180°≦θ≦360°180\degree\leqq\theta\leqq360\degree のときの sin⁡θ\sin\theta と cos⁡θ\cos\theta の値を調べてみましょう。(case3)、(case4) でやったように、単位円を用いることによって下の表が得られます(各自確認)。

     180°210°225°240°270°300°315°330°360°sin⁡0−12−22−32−1−3222−120cos⁡−1−32−22−12012 22 321\def\arraystretch{1.5} \begin{array}{c|c|c|c|c|c|c|c|c|c}   & 180\degree & 210\degree & 225\degree & 240\degree & 270\degree & 300\degree & 315\degree & 330\degree & 360\degree\\ \hline \sin & 0 & -\frac{1}{2} & -\frac{\sqrt{2}}{2} & -\frac{\sqrt{3}}{2} & -1 & -\frac{\sqrt{3}}{2} & \frac{\sqrt{2}}{2} & -\frac{1}{2} & 0\\ \hline \cos & -1 & -\frac{\sqrt{3}}{2} & -\frac{\sqrt{2}}{2} & -\frac{1}{2} & 0 & \frac{1}{2} & \frac{\sqrt{2}}{2} & \frac{\sqrt{3}}{2} & 1 \end{array}

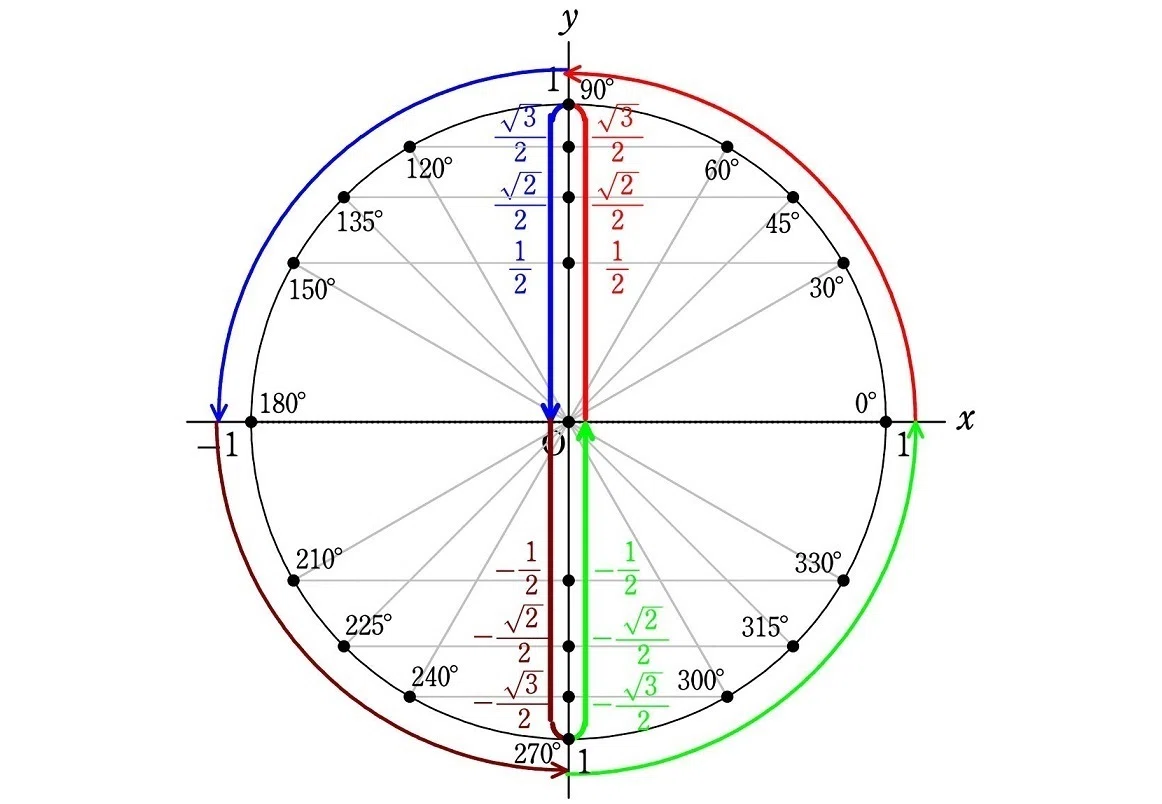
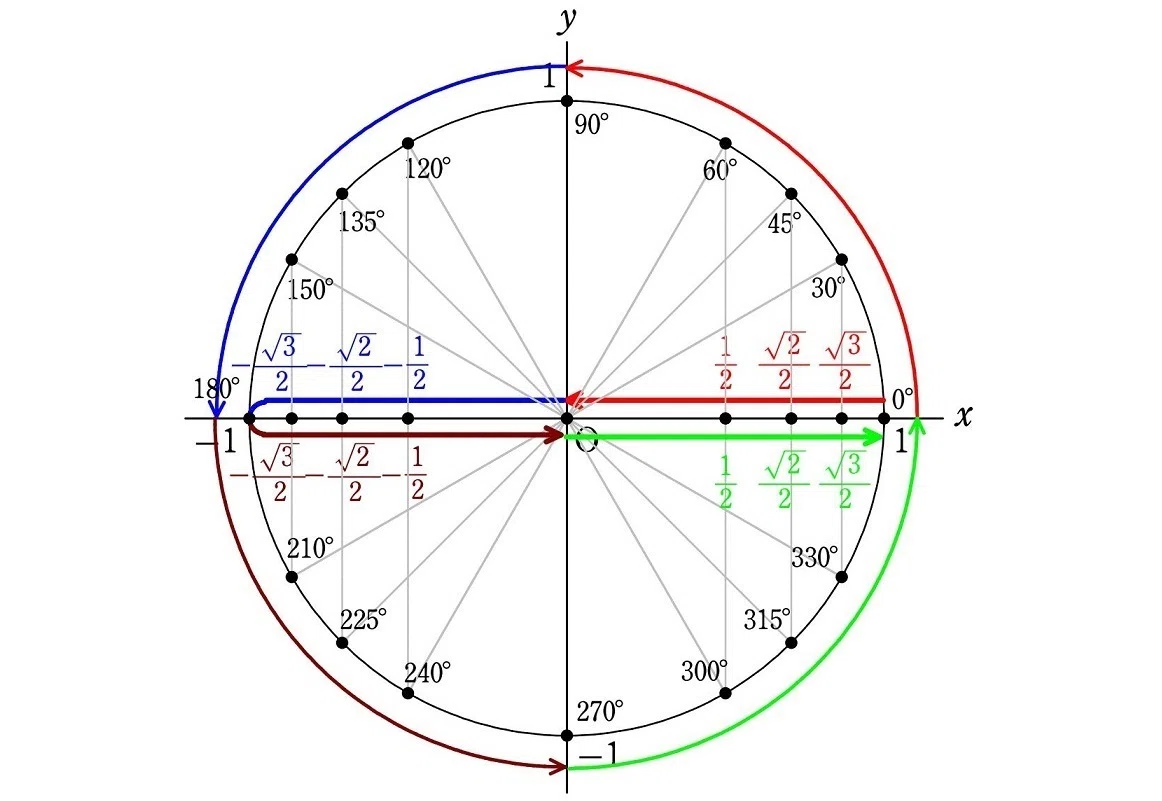
     θ\theta を 180°180\degree から大きくしていきましょう。
     sin⁡θ\sin\theta は yy 軸の動きをみます。
     180°180\degree を超えると、sin⁡θ\sin\theta はマイナスの値をとりながら
     −12, −22, −32-\dfrac{1}{2},  -\dfrac{\sqrt{2}}{2},  -\dfrac{\sqrt{3}}{2}
    と減少し(茶矢印)、最小値 −1-1 を境に、マイナスの値をとりながら
     −32, −22, −12-\dfrac{\sqrt{3}}{2},  -\dfrac{\sqrt{2}}{2},  -\dfrac{1}{2}
    と増加に転じで再び 00 になります(緑矢印)。

    画像

     cos⁡θ\cos\theta は xx 軸の動きをみます。
     cos⁡θ\cos\theta はマイナスの値をとりながら
     −32, −22, −12-\dfrac{\sqrt{3}}{2},  -\dfrac{\sqrt{2}}{2},  -\dfrac{1}{2}
    と増加し(茶矢印)、00 を境にプラスの値をとりながら
      12,  22,  32\dfrac{1}{2},   \dfrac{\sqrt{2}}{2},   \dfrac{\sqrt{3}}{2}
    とさらに増加し、再び最大値 11 になります(緑矢印)。

    画像

     円の回転と、その三角比の値がきちんと対応していることを是非とも確認ください。
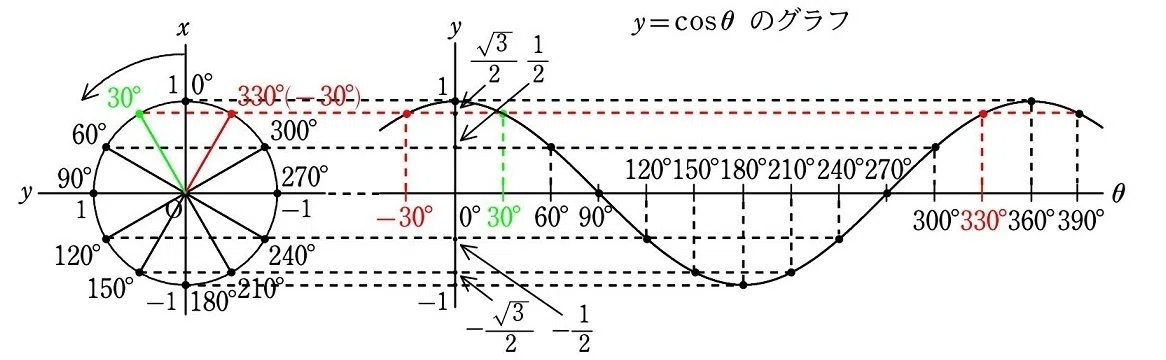
     これを書き足し、一般角で y=sin⁡θy=\sin\theta と y=cos⁡θy=\cos\theta のグラフを描くと下図のようになります。

    画像
    画像

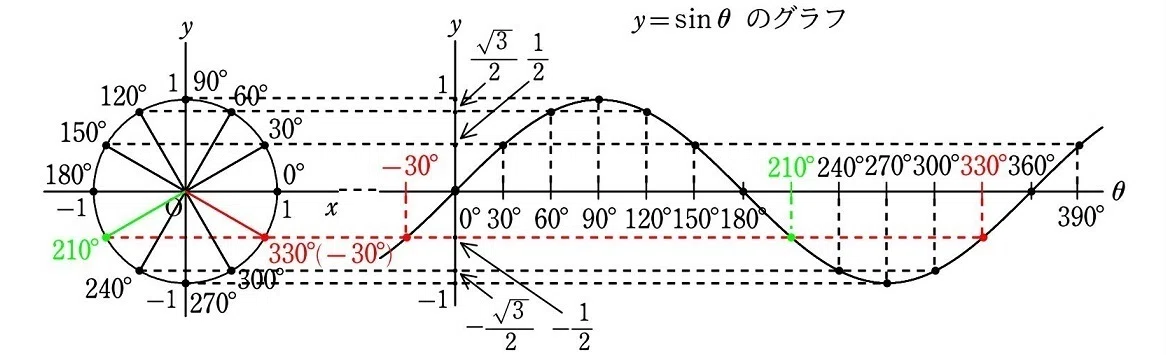
     一般角のところで、反時計回りを正の角、時計回りを負の角と定義しました。つまり −30°-30\degree とは、始線から時計回りに 30°30\degree 回転したときの角度です。
     このときの動径 OP\text{OP} は、始線から反時計回りに 330°330\degree 回転したときと同じになるので

    sin⁡(−30°)=sin⁡330°=−12cos⁡(−30°)=cos⁡330°=32\begin{alignat*}{3} &\sin(-30\degree) & &=\sin330\degree & &=-\dfrac{1}{2}\\[6pt] &\cos(-30\degree) & &=\cos330\degree & &=\dfrac{\sqrt{3}}{2} \end{alignat*}

    となります(下図の赤字)。
     なお、sin⁡θ\sin\theta に関しては 210°210\degree 回転したときとも同じ値になり、cos⁡θ\cos\theta に関しては 30°30\degree 回転したときとも同じ値になることを注意しておきます(下図の緑字)。

    画像
    画像

    sin⁡(−30°)=sin⁡225°=sin⁡330°=−12cos⁡(−30°)=cos⁡30°=cos⁡330°=32\begin{alignat*}{4} &\sin(-30\degree) & &=\sin225\degree & &=\sin330\degree & &=-\dfrac{1}{2}\\[6pt] &\cos(-30\degree) & &=\cos30\degree & &=\cos330\degree & &=\dfrac{\sqrt{3}}{2} \end{alignat*}

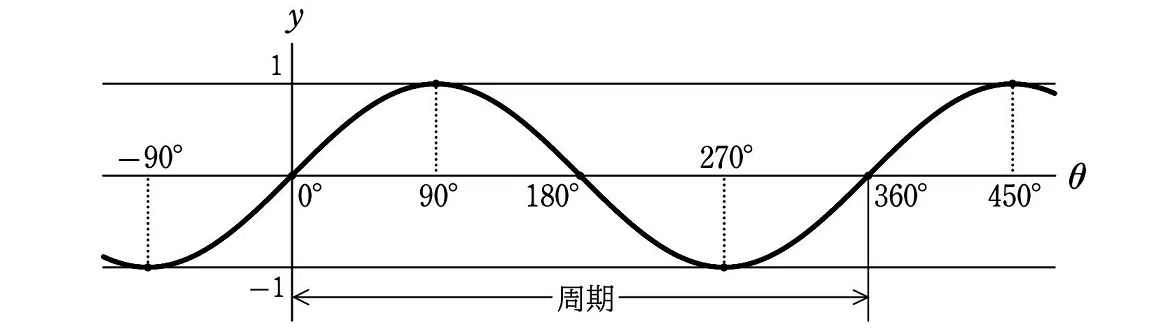
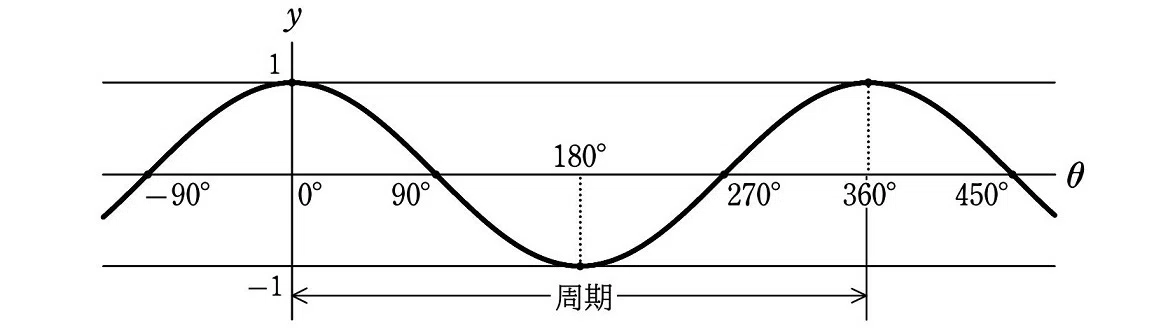
     以上より、y=sin⁡θy=\sin\theta と y=cos⁡θy=\cos\theta のグラフは次のようになります。

    y=sin⁡θy=\sin\theta のグラフ

    画像

    y=cos⁡θy=\cos\theta のグラフ

    画像

     どちらも 0°≦θ≦360°0\degree\leqq\theta\leqq360\degree の部分が繰り返し現れるので、周期は 360°360\degree です。また、yy の範囲(値域)はどちらも −1≦y≦1-1\leqq y \leqq1 です。
     y=sin⁡θy=\sin\theta のグラフを 90°90\degree だけマイナスの方向にずらすと、y=cos⁡θy=\cos\theta のグラフと重なります。

    tanθ のグラフ

     つぎは y=tan⁡θy=\tan\theta のグラフです。
     tan⁡θ\tan\theta は動径 OP\text{OP} の延長と直線 x=1x=1 との交点の yy 座標でした。
     前回やりましたが、0°≦θ≦180°0\degree\leqq\theta\leqq180\degree のときの tan⁡θ\tan\theta の値は次のようになります。

     0°30°45°60°90°120°135°150°180°tan⁡01313なし−3−1−130\def\arraystretch{1.5} \begin{array}{c|c|c|c|c|c|c|c|c|c}   & 0\degree & 30\degree & 45\degree & 60\degree & 90\degree & 120\degree & 135\degree & 150\degree & 180\degree\\ \hline \tan & 0 & \frac{1}{\sqrt{3}} & 1 & \sqrt{3} & {\small なし} & -\sqrt{3} & -1 & -\frac{1}{\sqrt{3}} & 0 \end{array}

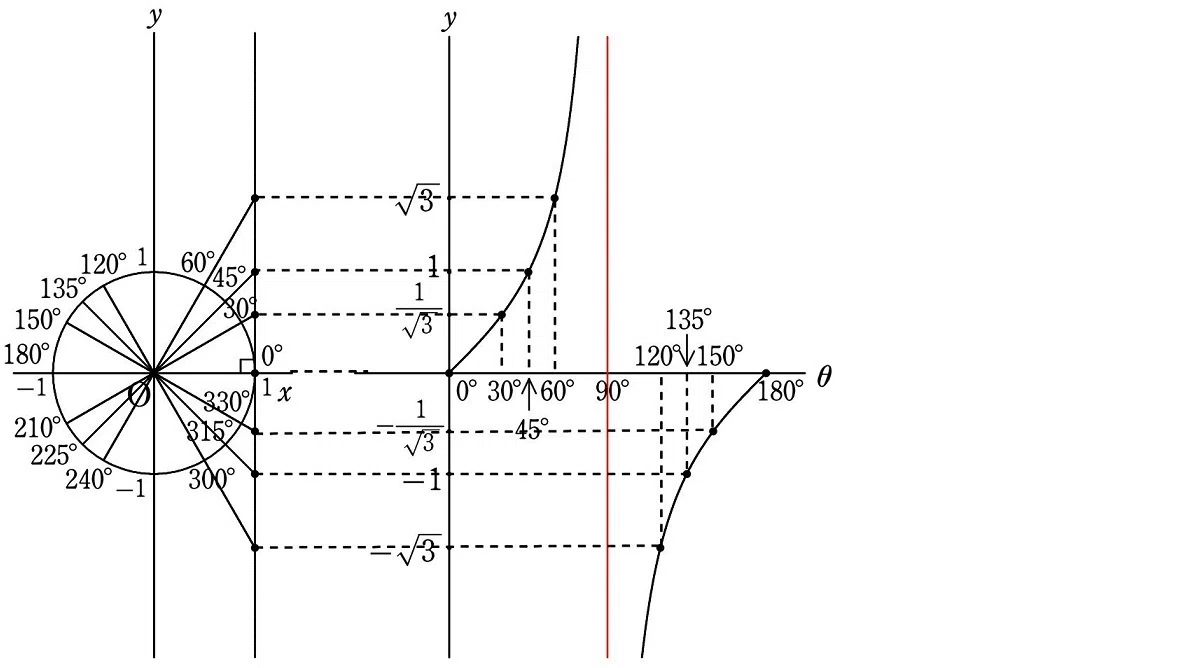
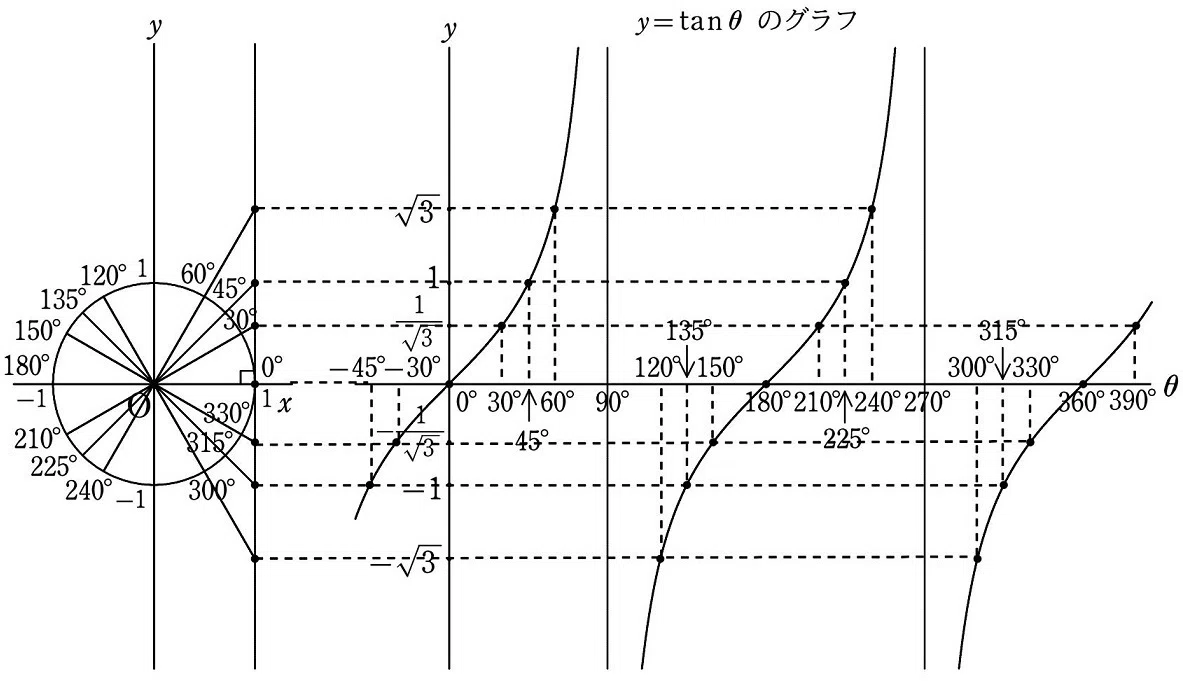
     関数 y=tan⁡θy=\tan\theta と見立てて、この値を y−θy-\theta 座標にプロットしていくと、下図のようになります。

    画像

     θ\theta が正の方向から 90°90\degree に近づくと、グラフは直線 y=90°y=90\degree(赤線)に限りなく近づいていくことが見て取れます。また、θ\theta が負の方向から 90°90\degree に近づいても、グラフは直線 θ=90°\theta=90\degree(赤線)に限りなく近づいていくことが見て取れます。ただ、どこまでも近づくだけであって、接したり交わることはありません。
     このように、接触しないで無限に近づいていく直線を漸近線といいます。

     これを、すべての角度 θ\theta に拡張します。
     はじめに、180°≦θ≦360°180\degree\leqq\theta\leqq360\degree のときの tan⁡θ\tan\theta  の値を調べてみましょう。(case3)、(case4) でやったように、単位円を用いることによって下の表が得られます(各自確認)。

     180°210°225°240°270°300°315°330°360°tan⁡01313なし−3−1−130\def\arraystretch{1.5} \begin{array}{c|c|c|c|c|c|c|c|c|c}   & 180\degree & 210\degree & 225\degree & 240\degree & 270\degree & 300\degree & 315\degree & 330\degree & 360\degree\\ \hline \tan & 0 & \frac{1}{\sqrt{3}} & 1 & \sqrt{3} & {\small なし} & -\sqrt{3} & -1 & -\frac{1}{\sqrt{3}} & 0 \end{array}

     θ\theta を 180°180\degree から大きくしていきましょう。
     tan⁡θ\tan\theta は yy 軸の動きをみます。
     tan⁡θ\tan\theta は、θ=180°\theta=180\degree のときは 00 で、そこからプラスの値をとりながら
      13,  1,  3\dfrac{1}{\sqrt{3}},   1,   \sqrt{3}
    と増加していき(茶矢印)、θ\theta が大きくなるにつれて tan⁡θ\tan\theta は無限大(限りなく大きい値)まで大きくなります。
     θ=270°\theta=270\degree のときは tan⁡θ\tan\theta は存在せず、θ=270°\theta=270\degree より大きい角度では、今度はマイナスの無限大から
      −3, −1, −13-\sqrt{3},  -1,  -\dfrac{1}{\sqrt{3}}
    とマイナスの値をとりながら増加していき(緑矢印)、θ=360°\theta=360\degree のときに再び 00 になります。

    画像

     これを書き足し、一般角で y=tan⁡θy=\tan\theta のグラフを描くと下図のようになります。

    画像

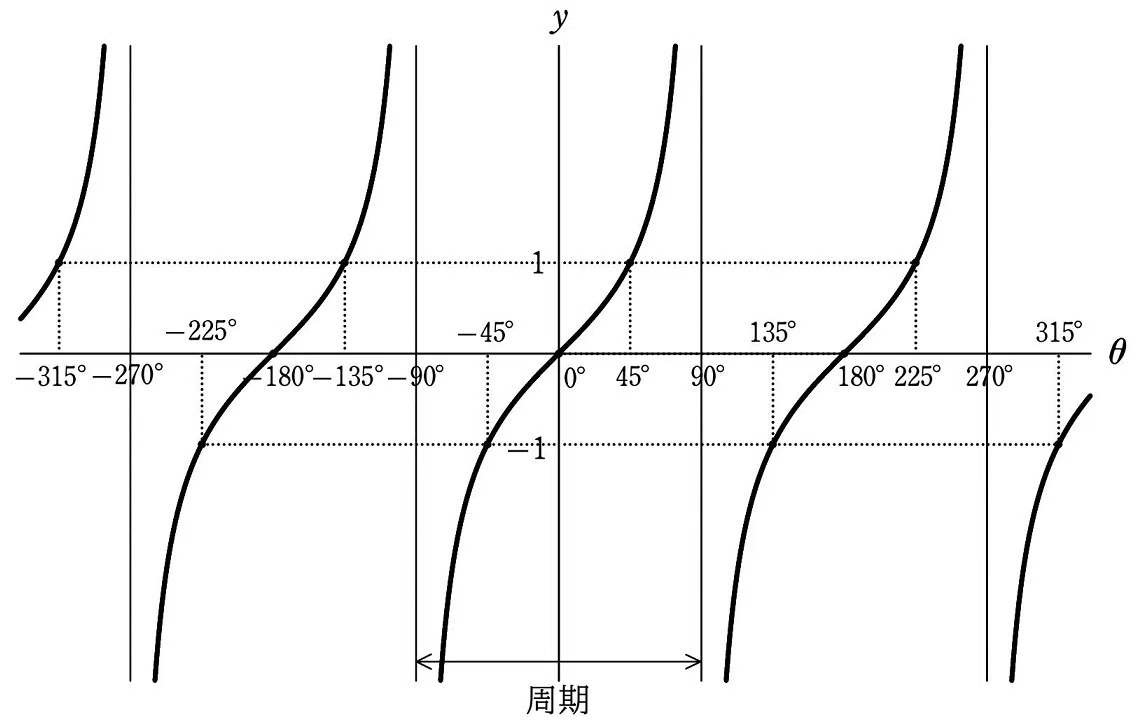
     以上より、y=tan⁡θy=\tan\theta のグラフは次のようになります。

    y=tan⁡θy=\tan\theta のグラフ

    画像

     −90°<θ<90°-90\degree<\theta<90\degree の部分が繰り返し現れるので、周期は 180°180\degree です。yy の範囲(値域)はすべての実数です。
     また、直線
     θ=−270°, −90°, 90°, 270°\theta=-270\degree,  -90\degree,  90\degree,  270\degree
    は漸近線で、漸近線は周期的にあらわれます。一般に漸近線は

    θ=90°+180°×n(nは整数)\begin{align*} \theta=90\degree+180\degree\times n{\small(n は整数)} \end{align*}

    となります。n=−2n=-2 のとき
     θ=90°+180°×(−2)=−270°\theta=90\degree+180\degree\times (-2)=-270\degree
    n=−1n=-1 のとき
     θ=90°+180°×(−1)=−90°\theta=90\degree+180\degree\times (-1)=-90\degree
    n=0n=0 のとき
     θ=90°+180°×0=90°\theta=90\degree+180\degree\times 0=90\degree
    n=1n=1 のとき
     θ=90°+180°×1=270°\theta=90\degree+180\degree\times 1=270\degree
    ⋮\hspace{23pt}\vdots
    以下同様となります。

    三角比・三角関数の重要公式

     高校で習う三角比・三角関数の公式です。主要なものを並べていきます。証明は教科書などを参照してください。前回やった三角比、およびその拡張としての三角関数の定義は非常にシンプルですが、ひとたびそのように定義すると、美しい公式が数多く現れることが驚きです。

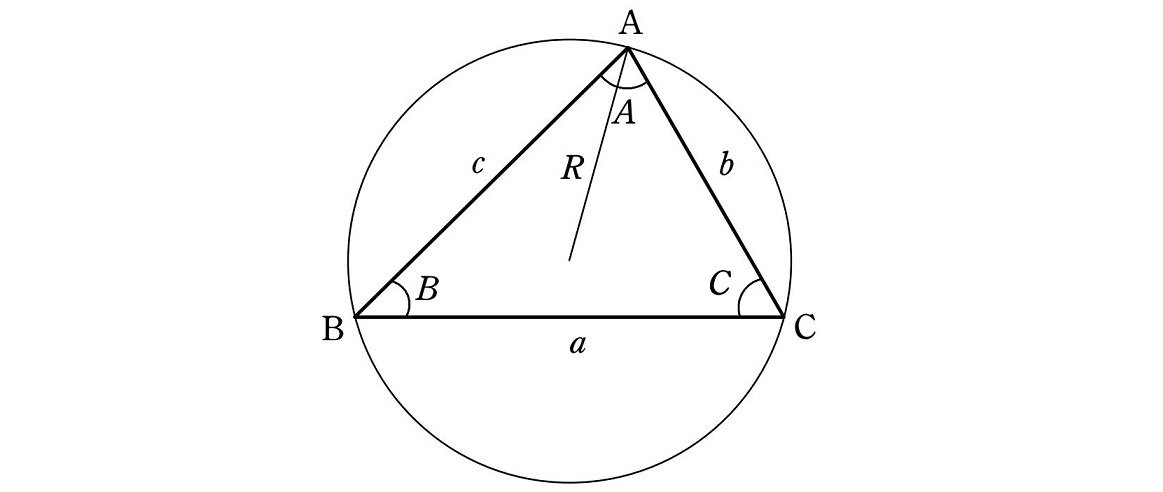
     次の △ABC\triangle\text{ABC} と外接円について

    画像

    <正弦定理>

     △ABC\triangle\text{ABC} の外接円の半径を RR とすると

    asin⁡A=bsin⁡B=csin⁡C=2R\begin{align*} \dfrac{a}{\sin A}=\dfrac{b}{\sin B}=\dfrac{c}{\sin C}=2R \end{align*}

    <余弦定理>

    a2=b2+c2−2bccos⁡Ab2=c2+a2−2cacos⁡Bc2=a2+b2−2abcos⁡C\begin{align*} a^2&=b^2+c^2-2bc\cos A\\ b^2&=c^2+a^2-2ca\cos B\\ c^2&=a^2+b^2-2ab\cos C \end{align*}

    <三角形の面積>

     △ABC\triangle\text{ABC} の面積を SS とすると

    S=12bcsin⁡A=12casin⁡B=12absin⁡C\begin{align*} S=\dfrac{1}{2}bc\sin A=\dfrac{1}{2}ca\sin B=\dfrac{1}{2}ab\sin C \end{align*}

     ここまでは、三角形の内角で定義された公式です。
     次からは三角形の図形的制約から放れ、一般角 θ, α, β\theta,  \alpha,  \beta について成り立つ公式です。

    <三角関数の相互関係>

    sin⁡2θ+cos⁡2θ=1tan⁡θ=tan⁡θcos⁡θ1+tan⁡2θ=1cos⁡2θ\begin{align*} &\sin^2\theta+\cos^2\theta=1\\[6pt] &\tan\theta=\dfrac{\tan\theta}{\cos\theta}\\[6pt] &1+\tan^2\theta=\dfrac{1}{\cos^2\theta} \end{align*}

    <加法定理>

    sin⁡(α+β)=sin⁡αcos⁡β+cos⁡αsin⁡βsin⁡(α−β)=sin⁡αcos⁡β−cos⁡αsin⁡βcos⁡(α+β)=cos⁡αcos⁡β−sin⁡αsin⁡βcos⁡(α−β)=cos⁡αcos⁡β+sin⁡αsin⁡βtan⁡(α+β)=tan⁡α+tan⁡β1−tan⁡αtan⁡βtan⁡(α−β)=tan⁡α−tan⁡β1+tan⁡αtan⁡β\begin{alignat*}{2} &\sin(\alpha+\beta) & &=\sin\alpha\cos\beta+\cos\alpha\sin\beta\\ &\sin(\alpha-\beta) & &=\sin\alpha\cos\beta-\cos\alpha\sin\beta\\ &\cos(\alpha+\beta) & &=\cos\alpha\cos\beta-\sin\alpha\sin\beta\\ &\cos(\alpha-\beta) & &=\cos\alpha\cos\beta+\sin\alpha\sin\beta\\ &\tan(\alpha+\beta) & &=\dfrac{\tan\alpha+\tan\beta}{1-\tan\alpha\tan\beta}\\[8pt] &\tan(\alpha-\beta) & &=\dfrac{\tan\alpha-\tan\beta}{1+\tan\alpha\tan\beta} \end{alignat*}

    <2倍角の公式>

    sin⁡2α=2sin⁡αcos⁡βcos⁡2α=cos⁡2α−sin⁡2α=1−2sin⁡2α=2cos⁡2α−1tan⁡2α=2tan⁡α1−tan⁡2α\begin{alignat*}{2} &\sin2\alpha & &=2\sin\alpha\cos\beta\\ &\cos2\alpha & &=\cos^2\alpha-\sin^2\alpha\\ & & &=1-2\sin^2\alpha\\ & & &=2\cos^2\alpha-1\\ &\tan2\alpha & &=\dfrac{2\tan\alpha}{1-\tan^2\alpha} \end{alignat*}

    <半角の公式>

    sin⁡2α2=1−cos⁡α2cos⁡2α2=1+cos⁡α2tan⁡2α2=1−cos⁡α1+cos⁡α\begin{alignat*}{2} &\sin^2\dfrac{\alpha}{2} & &=\dfrac{1-\cos\alpha}{2}\\[6pt] &\cos^2\dfrac{\alpha}{2} & &=\dfrac{1+\cos\alpha}{2}\\[6pt] &\tan^2\dfrac{\alpha}{2} & &=\dfrac{1-\cos\alpha}{1+\cos\alpha} \end{alignat*}

    弧度法

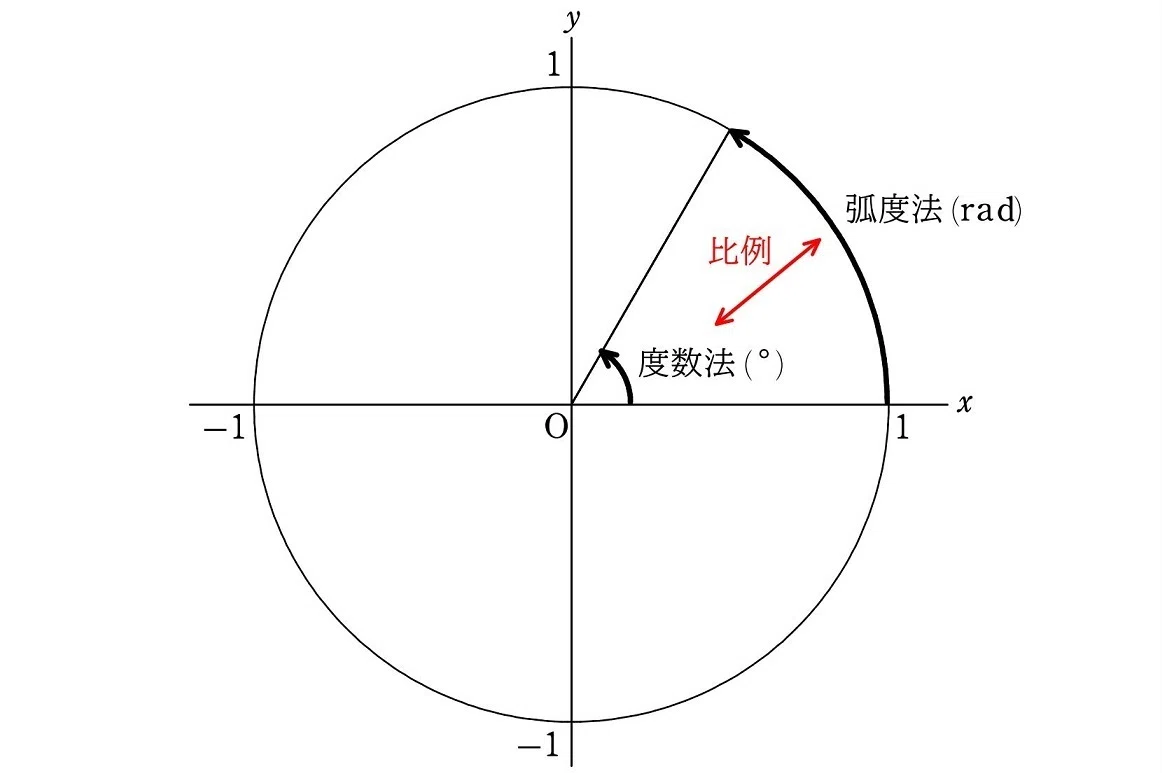
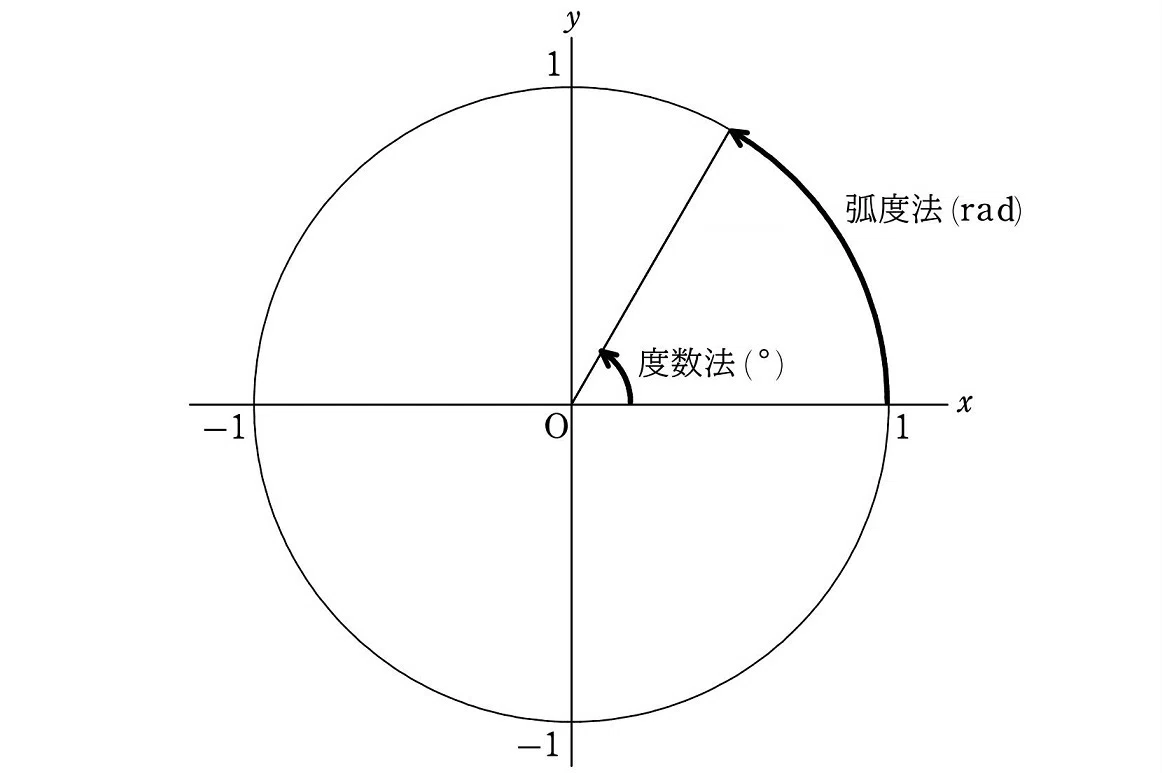
     三角関数の角度の表し方として、今までは度数法で表してきました。度数法とは「度 (°\degree)」という単位を用いた、小学校で習う角度の表し方です(いわゆる分度器の角度)。
     この角度を、その中心角に対する「単位円の弧の長さ」で表す方法を弧度法といいます。弧度法の単位はラジアン (rad) です。円の"弧"で"角度"を表す方法です。
    画像

     一周の角度の大きさは、度数法では 360°360\degree です。単位円の円周(一周)の長さは 2π2\pi なので、360°360\degree に対応する角度は、弧度法では 2π2\pi ラジアンになります。

    360°⟷ 2π ラジアン\begin{align*} 360\degree \longleftrightarrow  2\pi  \small{ラジアン} \end{align*}

     弧度法では、単位のラジアンを省略して、360°360\degree を単に 2π2\pi と書きます。

    360°⟷ 2π\begin{align*} 360\degree \longleftrightarrow  2\pi \end{align*}

     すると、中心角(度数法)と、それに対する弧の長さは比例するので

    画像

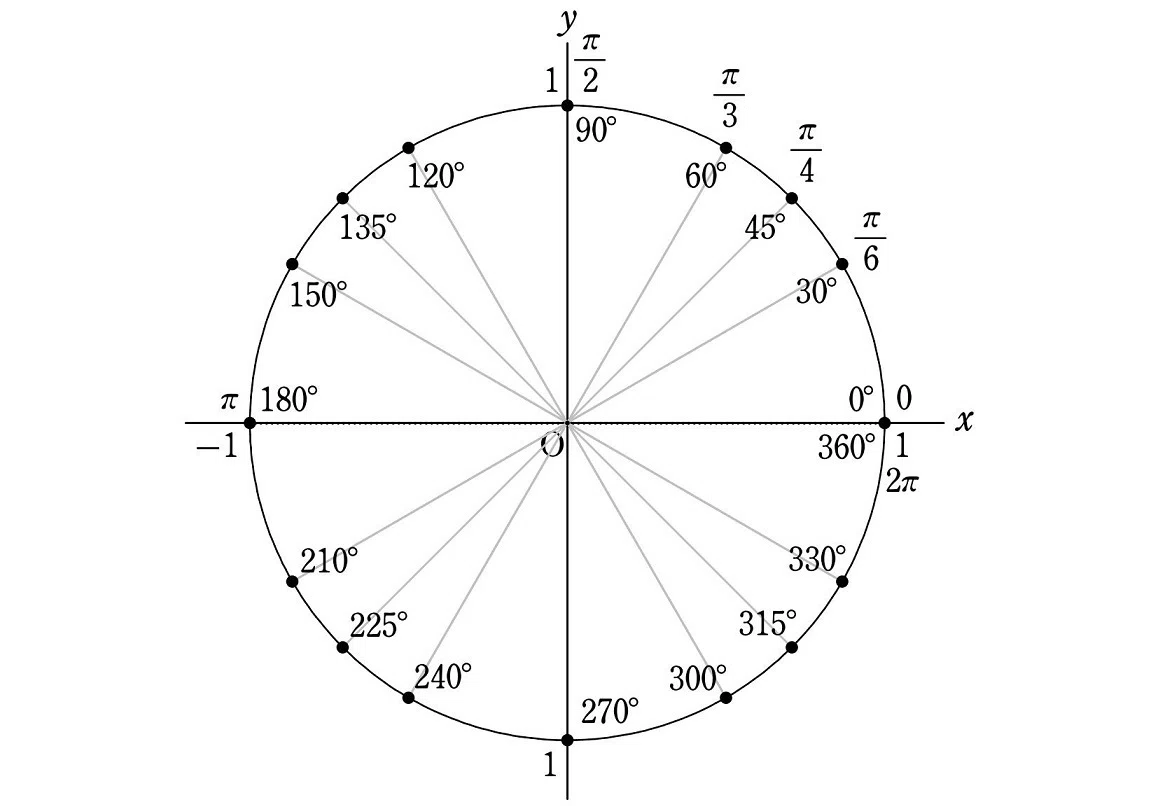
    この「360°⟷ 2π360\degree \longleftrightarrow  2\pi」を基準に、その 12\dfrac{1}{2} 倍、14\dfrac{1}{4} 倍、⋯\cdots と刻んでいくことによって、次のように度数法と弧度法の対応関係が分かります。いわゆる有名角の弧度法です。

    360°⟷ 2π  基準180°⟷ π基準の 12 倍90°⟷ π2基準の 14 倍60°⟷ π3基準の 16 倍45°⟷ π4基準の 18 倍30°⟷ π6基準の 112 倍0°⟷ 0基準の 0 倍\begin{alignat*}{2} 360\degree &\longleftrightarrow  2\pi &   &\small{基準}\\[6pt] 180\degree &\longleftrightarrow  \pi & &\small{基準の  \dfrac{1}{2}  倍}\\[6pt] 90\degree &\longleftrightarrow  \dfrac{\pi}{2} & &\small{基準の  \dfrac{1}{4}  倍}\\[6pt] 60\degree &\longleftrightarrow  \dfrac{\pi}{3} & &\small{基準の  \dfrac{1}{6}  倍}\\[6pt] 45\degree &\longleftrightarrow  \dfrac{\pi}{4} & &\small{基準の  \dfrac{1}{8}  倍}\\[6pt] 30\degree &\longleftrightarrow  \dfrac{\pi}{6} & &\small{基準の  \dfrac{1}{12}  倍}\\[8pt] 0\degree &\longleftrightarrow  0 & &\small{基準の  0  倍} \end{alignat*}

     単位円で書くと次のようになります。内側が度数法、外側が弧度法です。

    画像

     例えば、30°30\degree は弧度法では π6\dfrac{\pi}{6}、45°45\degree は弧度法では π4\dfrac{\pi}{4} となります。頻繁に出てくるので、上記の値は覚えておくのがよいでしょう。
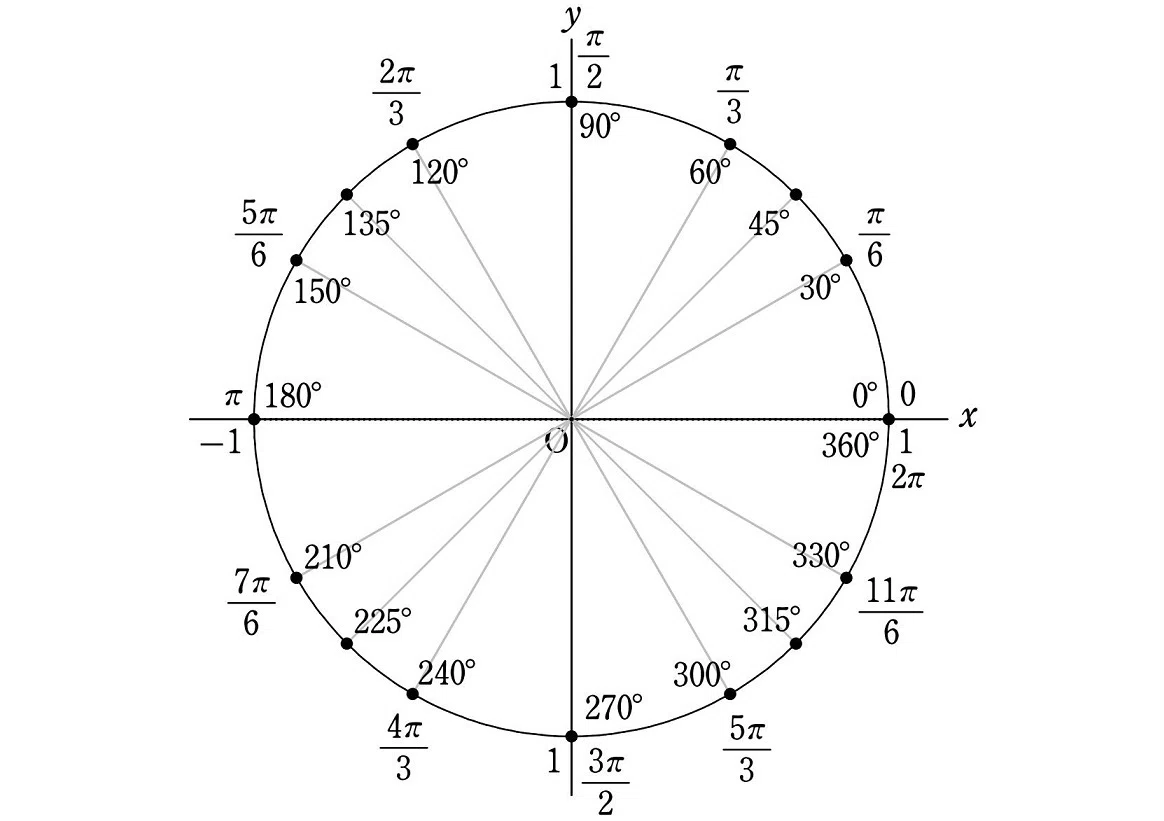
     すると、この最小単位である「30°⟷ π630\degree \longleftrightarrow  \dfrac{\pi}{6}」を基準にして、その 22 倍、33 倍、⋯\cdots を考えることによって、30°30\degree 刻みの弧度法が求まります。下線部があらたに求められた値です。

    30°⟷ π6  基準60°⟷ 2π6=π3基準の 2 倍90°⟷ 3π6=π2基準の 3 倍120°‾⟷ 4π6=2π3基準の 4 倍150°‾⟷ 5π6基準の 5 倍180°⟷ 9π6=π基準の 6 倍210°‾⟷ 7π6基準の 7 倍240°‾⟷ 8π6=4π3基準の 8 倍270°‾⟷ 9π6=3π2基準の 9 倍300°‾⟷ 10π6=5π4基準の 10 倍330°‾⟷ 11π6基準の 11 倍360°⟷ 12π6=2π基準の 12 倍\begin{alignat*}{2} 30\degree &\longleftrightarrow  \dfrac{\pi}{6} &   &\small{基準}\\[6pt] 60\degree &\longleftrightarrow  \dfrac{2\pi}{6}=\dfrac{\pi}{3} & &\small{基準の  2  倍}\\[6pt] 90\degree &\longleftrightarrow  \dfrac{3\pi}{6}=\dfrac{\pi}{2} & &\small{基準の  3  倍}\\[6pt] \underline{120\degree} &\longleftrightarrow  \dfrac{4\pi}{6}=\dfrac{2\pi}{3} & &\small{基準の  4  倍}\\[6pt] \underline{150\degree} &\longleftrightarrow  \dfrac{5\pi}{6} & &\small{基準の  5  倍}\\[6pt] 180\degree &\longleftrightarrow  \dfrac{9\pi}{6}=\pi & &\small{基準の  6  倍}\\[6pt] \underline{210\degree} &\longleftrightarrow  \dfrac{7\pi}{6} & &\small{基準の  7  倍}\\[6pt] \underline{240\degree} &\longleftrightarrow  \dfrac{8\pi}{6}=\dfrac{4\pi}{3} & &\small{基準の  8  倍}\\[6pt] \underline{270\degree} &\longleftrightarrow  \dfrac{9\pi}{6}=\dfrac{3\pi}{2} & &\small{基準の  9  倍}\\[6pt] \underline{300\degree} &\longleftrightarrow  \dfrac{10\pi}{6}=\dfrac{5\pi}{4} & &\small{基準の  10  倍}\\[6pt] \underline{330\degree} &\longleftrightarrow  \dfrac{11\pi}{6} & &\small{基準の  11  倍}\\[6pt] 360\degree &\longleftrightarrow  \dfrac{12\pi}{6}=2\pi & &\small{基準の  12  倍}\\[6pt] \end{alignat*}

    画像

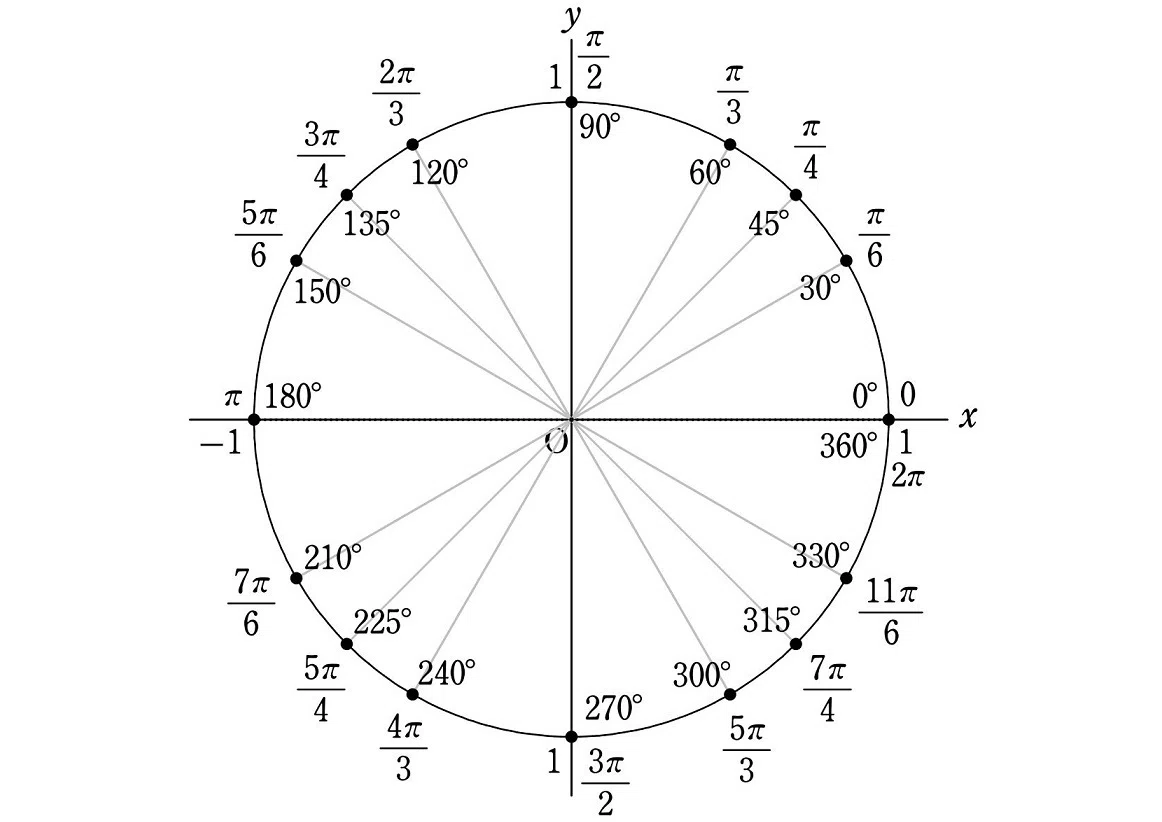
     これに、今度は「45°⟷ π445\degree \longleftrightarrow  \dfrac{\pi}{4}」を基準にして、その 22 倍、33 倍、⋯\cdots を考えることによって、45°45\degree 刻みの弧度法が求まります。下線部があらたに求められた値です。

    45°⟷ π4  基準90°⟷ 2π4=π2基準の 2 倍135°‾⟷ 3π4基準の 3 倍180°⟷ 4π4=π基準の 4 倍225°‾⟷ 5π4基準の 5 倍270°⟷ 6π4=3π2基準の 6 倍315°‾⟷ 7π4基準の 7 倍360°⟷ 8π4=2π基準の 8 倍\begin{alignat*}{2} 45\degree &\longleftrightarrow  \dfrac{\pi}{4} &   &\small{基準}\\[6pt] 90\degree &\longleftrightarrow  \dfrac{2\pi}{4}=\dfrac{\pi}{2} & &\small{基準の  2  倍}\\[6pt] \underline{135\degree} &\longleftrightarrow  \dfrac{3\pi}{4} & &\small{基準の  3  倍}\\[6pt] 180\degree &\longleftrightarrow  \dfrac{4\pi}{4}=\pi & &\small{基準の  4  倍}\\[6pt] \underline{225\degree} &\longleftrightarrow  \dfrac{5\pi}{4} & &\small{基準の  5  倍}\\[6pt] 270\degree &\longleftrightarrow  \dfrac{6\pi}{4}=\dfrac{3\pi}{2} & &\small{基準の  6  倍}\\[6pt] \underline{315\degree} &\longleftrightarrow  \dfrac{7\pi}{4} & &\small{基準の  7  倍}\\[6pt] 360\degree &\longleftrightarrow  \dfrac{8\pi}{4}=2\pi & &\small{基準の  8  倍} \end{alignat*}

    画像

     さらに「60°⟷ π360\degree \longleftrightarrow  \dfrac{\pi}{3}」を基準にして、その 22 倍、33 倍、⋯\cdots を考えることもできますが、それらの値はすでに求めています。
     以上で、単位円周上の主要な角度について、度数法を弧度法に変換することができました。分母に現れる数を見て「6432346」とリズムで覚えてもよいでしょう。
     あとは度数法と同じように、反時計回りをプラス(2周目からは 2π2\pi よりも大きい角度)、時計回りをマイナスで表すことによって、弧度法による三角関数を考えることができます。

    三角比の表(弧度法)

     参考までに、弧度法で考えた時の三角関数の表です。00 から π\pi の範囲で与えます。ぱっとすぐに引き出せることが重要です。
     特に、鋭角の場合は覚えておくのがよいでしょう。鋭角の場合を覚えておけば、それを基準に、単位円上の回転や線対称で移すなどして他の値も引き出しやすくなります。度数法と同じなので、単位円を描いて導き出せるようにしましょう。

    sin⁡0=0cos⁡0=1tan⁡0=0sin⁡π6=12cos⁡π6=32tan⁡π6=13sin⁡π4=22cos⁡π4=22tan⁡π4=1sin⁡π3=32cos⁡π3=12tan⁡π3=3sin⁡π2=1cos⁡π2=0tan⁡π2 はなしsin⁡2π3=32cos⁡2π3=−12tan⁡2π3=−3sin⁡3π4=22cos⁡3π4=−22tan⁡3π4=−1sin⁡5π6=12cos⁡5π6=−32tan⁡5π6=−13sin⁡π=0cos⁡π=−1tan⁡π=0\begin{alignat*}{3} &\sin 0=0\hspace{32pt} & &\cos 0=1\hspace{32pt} & &\tan 0=0\\[6pt] &\sin \dfrac{\pi}{6}=\dfrac{1}{2} & &\cos \dfrac{\pi}{6}=\dfrac{\sqrt{3}}{2} & &\tan \dfrac{\pi}{6}=\dfrac{1}{\sqrt{3}}\\[6pt] &\sin \dfrac{\pi}{4}=\dfrac{\sqrt{2}}{2} & &\cos \dfrac{\pi}{4}=\dfrac{\sqrt{2}}{2} & &\tan \dfrac{\pi}{4}=1\\[6pt] &\sin \dfrac{\pi}{3}=\dfrac{\sqrt{3}}{2} & &\cos \dfrac{\pi}{3}=\dfrac{1}{2} & &\tan \dfrac{\pi}{3}=\sqrt{3}\\[8pt] &\sin \dfrac{\pi}{2}=1 & &\cos \dfrac{\pi}{2}=0 & &\tan \dfrac{\pi}{2}  {\small はなし}\\[6pt] &\sin \dfrac{2\pi}{3}=\dfrac{\sqrt{3}}{2} & &\cos \dfrac{2\pi}{3}=-\dfrac{1}{2} & &\tan \dfrac{2\pi}{3}=-\sqrt{3}\\[6pt] &\sin \dfrac{3\pi}{4}=\dfrac{\sqrt{2}}{2} & &\cos \dfrac{3\pi}{4}=-\dfrac{\sqrt{2}}{2} & &\tan \dfrac{3\pi}{4}=-1\\[6pt] &\sin \dfrac{5\pi}{6}=\dfrac{1}{2} & &\cos \dfrac{5\pi}{6}=-\dfrac{\sqrt{3}}{2} & &\tan \dfrac{5\pi}{6}=-\dfrac{1}{\sqrt{3}}\\[10pt] &\sin \pi=0\hspace{32pt} & &\cos \pi=-1\hspace{32pt} & &\tan \pi=0 \end{alignat*}

    三角関数のグラフ(弧度法)

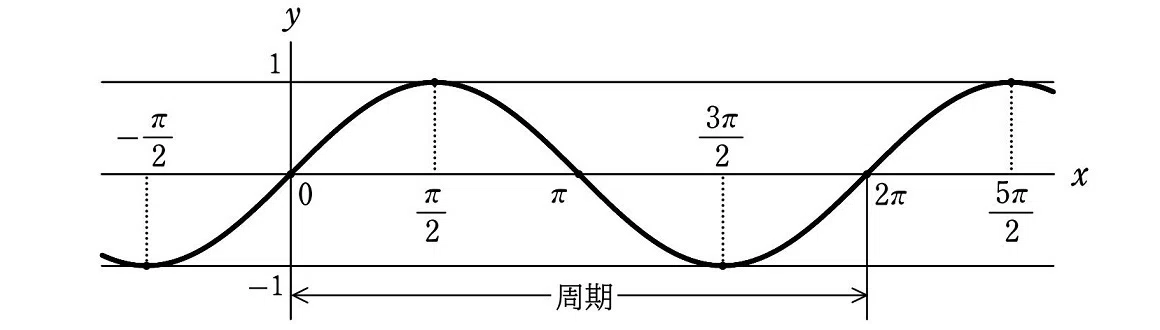
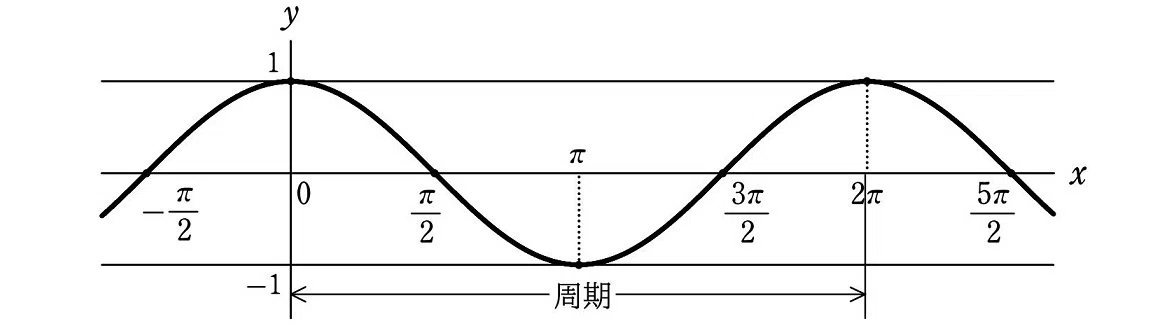
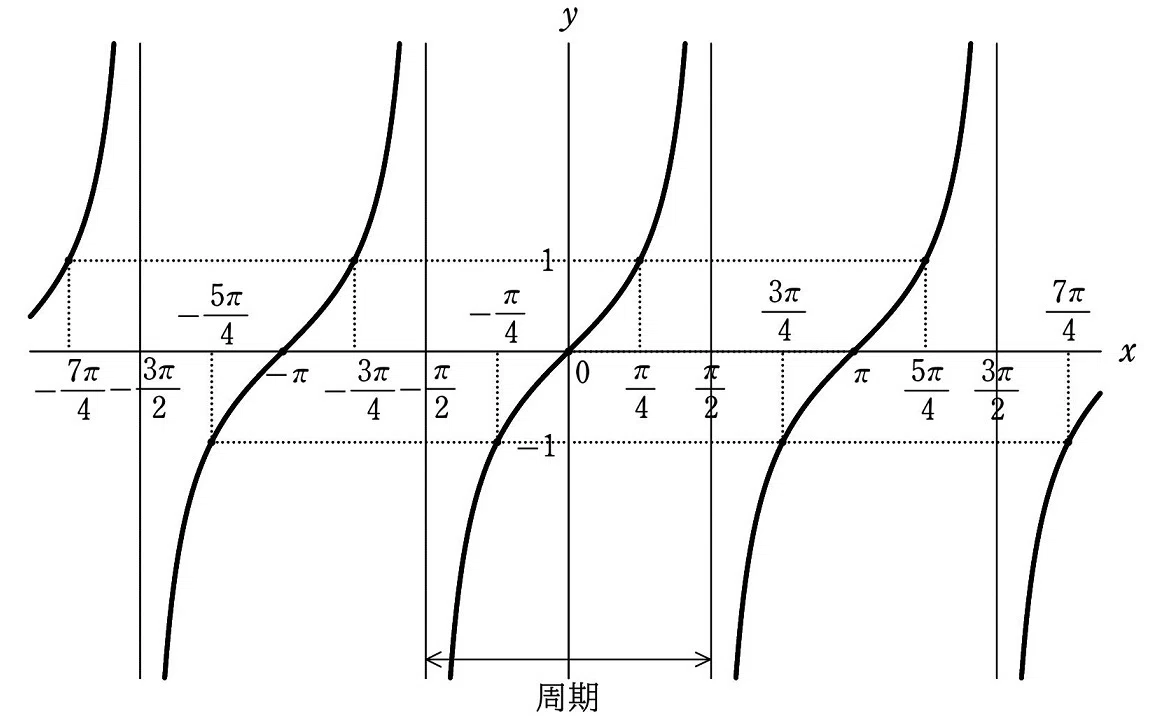
     弧度法で表したときのそれぞれの三角関数のグラフは、次のようになります。弧度法のときは xx の関数として考えます(θ\theta は度数法)。見慣れた x−yx-y 座標でのグラフです。

    y=sin⁡xy=\sin x のグラフ

    画像

    y=cos⁡xy=\cos x のグラフ

    画像

    y=tan⁡xy=\tan x のグラフ

    画像

     弧度法を導入することによって、xx 軸と yy 軸で同じ実数値のメモリを使うことになり、次のように三角関数の微分積分が美しく求まります。これが弧度法で考えるメリットの1つです。高校の数学Ⅲ以降、大学の数学では弧度法が使われます。

    <三角関数の微分>

    (sin⁡x)′=cos⁡x(cos⁡x)′=−sin⁡x(tan⁡x)′=1cos⁡2x\begin{alignat*}{2} &(\sin x)' & &=\cos x\\[5pt] &(\cos x)' & &=-\sin x\\ &(\tan x)' & &=\dfrac{1}{\cos^2x} \end{alignat*}

    <三角関数の積分>

    ∫sin⁡x dx=−cos⁡x+c∫cos⁡x dx=sin⁡x+c∫1cos⁡2xdx=tan⁡x+c\begin{alignat*}{2} &\int\sin x\,dx& &=-\cos x+c\\ &\int\cos x\,dx& &=\sin x+c\\ &\int\dfrac{1}{\cos^2x}dx& &=\tan x+c \end{alignat*}

     なお、tan⁡x\tan x そのものの積分は公式ではないですが、次の結果が得られます。

    ∫tan⁡x dx=−log⁡∣tan⁡x∣+C\begin{align*} \int\tan x\,dx=-\log|\tan x|+C \end{align*}

    三角比の歴史(再掲)

    (前回の「三角比」でも書いた記事の再掲です。三角関数の歴史を加筆したかったのですが、調べても詳しい歴史が分からないのでそのまま再掲します。なにか新しいことが分かったら加筆予定。)

     三角比の起源は、紀元前の三角法にさかのぼります。三角法とは、直角三角形の辺の比と角度を用いた、図形に関する計算方法です。測量、航海、天文学などの実用上の必要により、古代から研究されてきました。
     古代ギリシャの数学者、天文学者である、ヒッパルコスは、円周角と弦の長さの対応表(今の三角比の表の原型となるもの)を作り、幾何学の研究や測量を行いました。これによりヒッパルコスは「三角法の父」とよばれています。
    画像

     なお、高校で習う三角比の定義は、ヒッパルコスによるものではなく、スイスの数学者、レオンハルト・オイラーが最初だといわれています。
    画像

     オイラーは三角比を円関数として見直すことで(まさに単位円の考え方)、一般の角度(一般角)θ\theta に対して sin⁡θ, cos⁡θ, tan⁡θ\sin\theta,  \cos\theta,  \tan\theta を定義しました。三角関数の誕生です。

    数式ミステリー


    この記事が参加している募集

    あなたへのおすすめ